

An MRF Model Based Approachfor Sub-pixel Mapping from Hyperspectral Data
275
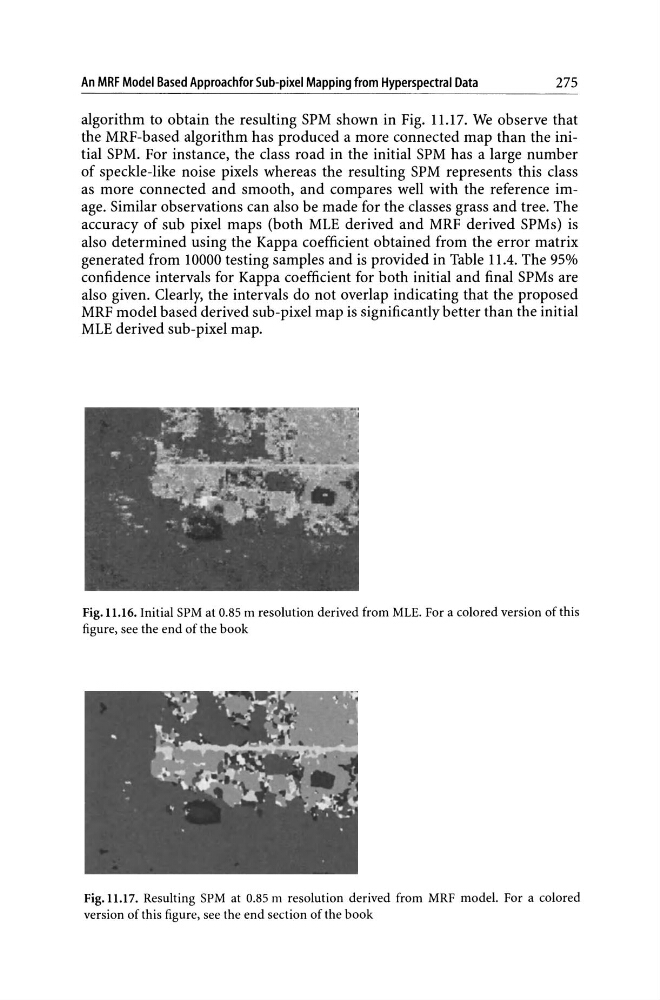
algorithm to obtain the resulting SPM shown in Fig. 11.17. We observe that
the MRF-based algorithm has produced a more connected map than the initial SPM. For instance, the class road in the initial SPM has a large number
of speckle-like noise pixels whereas the resulting SPM represents this class
as more connected and smooth, and compares well with the reference image. Similar observations can also be made for the classes grass and tree. The
accuracy of sub pixel maps (both MLE derived and MRF derived SPMs) is
also determined using the Kappa coefficient obtained from the error matrix
generated from 10000 testing samples and is provided in Table 1104. The 95%
confidence intervals for Kappa coefficient for both initial and final SPMs are
also given. Clearly, the intervals do not overlap indicating that the proposed
MRF model based derived sub-pixel map is significantly better than the initial
MLE derived sub-pixel map.
Fig. 11.16. Initial SPM at 0.85 m resolution derived from MLE. For a colored version of this
figure, see the end of the book
Fig. 11.17. Resulting SPM at 0.85 m resolution derived from MRF model. For a colored
version of this figure, see the end section of the book