

162
6: Teerasit Kasetkasem
The subset Ns is called the neighborhood of the site s. The pair (-8, N) is called
a graph, or a topology. The boundary of A C -8 is the set aA = (U Ns) \A
SEA
where B\A denotes the complement of A in B.
6.2.1.3
Markov Random Field
A random field X is called a Markov random field (MRF) with respect to the
neighborhood system N iffor all sites s E -8, the random variables X(s) and
X (-8\Ns) are independent given X(NJ where Ns is defined as Ns U Is}.
The above definition can also be written in a mathematical form as
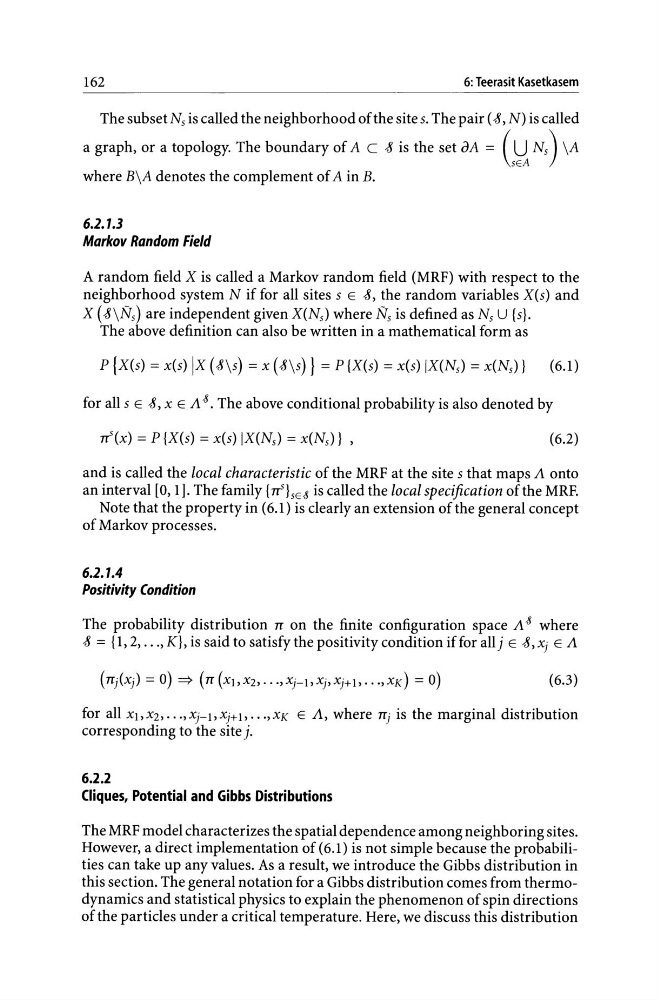
P {X(s) = x(s) IX (-8\s) = x (-8\s) } = P (X(s) = x(s) IX(Ns) = x(Ns)} (6.1)
for all s E -8, x E il s. The above conditional probability is also denoted by
(6.2)
and is called the local characteristic of the MRF at the site s that maps il onto
an interval [0, 1]. The family {If} SES is called the local specification of the MRF.
Note that the property in (6.1) is clearly an extension of the general concept
of Markov processes.
6.2.1.4
Positivity Condition
The probability distribution Tf on the finite configuration space il S where
-8 = {I, 2, ... , K}, is said to satisfy the positivity condition iffor all j E -8, Xj E il
(6.3)
for all Xl, X2, ••• , Xj-l, Xj+ I, ... , XK E il, where Tfj is the marginal distribution
corresponding to the site j.
6.2.2
Cliques, Potential and Gibbs Distributions
The MRF model characterizes the spatial dependence among neighboring sites.
However, a direct implementation of (6.1) is not simple because the probabilities can take up any values. As a result, we introduce the Gibbs distribution in
this section. The general notation for a Gibbs distribution comes from thermodynamics and statistical physics to explain the phenomenon of spin directions
of the particles under a critical temperature. Here, we discuss this distribution