

15 Ship Surveillance with High Resolution TerraSAR-X Satellite in African Waters
305
component, while the second is related to the range velocity component as will be
described in the following.
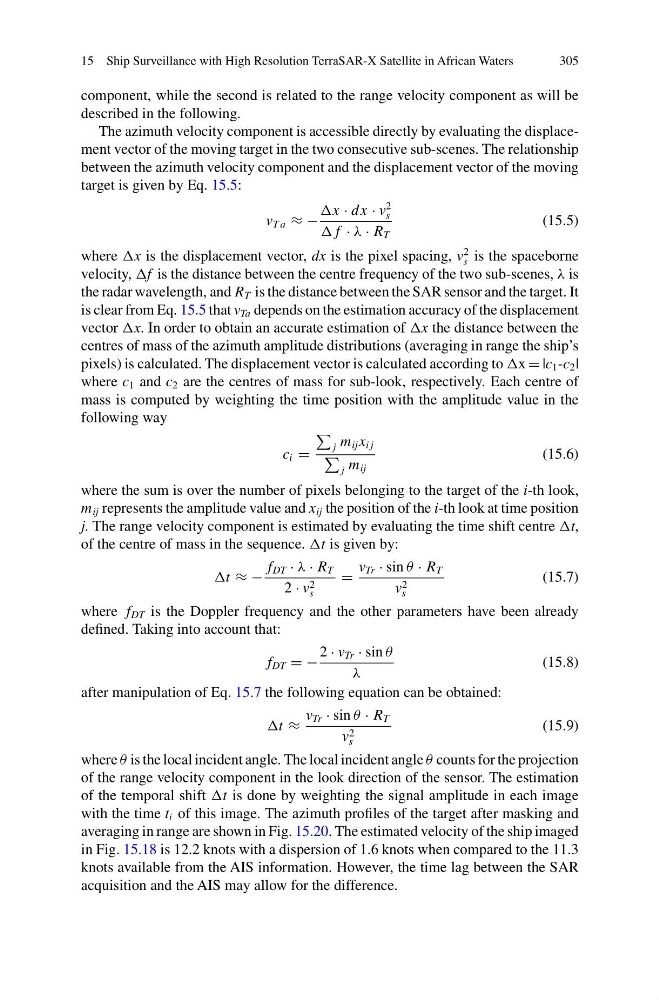
The azimuth velocity component is accessible directly by evaluating the displacement vector of the moving target in the two consecutive sub-scenes. The relationship
between the azimuth velocity component and the displacement vector of the moving
target is given by Eq. 15.5:
v T a ≈ −
Δx · dx · v
2
s
Δf · λ · R T
(15.5)
where Δx is the displacement vector, dx is the pixel spacing, v
2
s is the spaceborne
velocity, Δf is the distance between the centre frequency of the two sub-scenes, λ is
the radar wavelength, and R T is the distance between the SAR sensor and the target. It
is clear from Eq. 15.5 that v Ta depends on the estimation accuracy of the displacement
vector Δx. In order to obtain an accurate estimation of Δx the distance between the
centres of mass of the azimuth amplitude distributions (averaging in range the ship’s
pixels) is calculated. The displacement vector is calculated according to Δx = |c 1 -c 2 |
where c 1 and c 2 are the centres of mass for sub-look, respectively. Each centre of
mass is computed by weighting the time position with the amplitude value in the
following way
c i =
j m ij x ij
j m ij
(15.6)
where the sum is over the number of pixels belonging to the target of the i-th look,
m ij represents the amplitude value and x ij the position of the i-th look at time position
j. The range velocity component is estimated by evaluating the time shift centre Δt,
of the centre of mass in the sequence. Δt is given by:
Δt ≈ −
f DT · λ · R T
2 · v 2
s
=
v Tr · sin θ · R T
v 2
s
(15.7)
where f DT is the Doppler frequency and the other parameters have been already
defined. Taking into account that:
f DT = −
2 · v Tr · sin θ
λ
(15.8)
after manipulation of Eq. 15.7 the following equation can be obtained:
Δt ≈
v Tr · sin θ · R T
v 2
s
(15.9)
where θ is the local incident angle. The local incident angle θ counts for the projection
of the range velocity component in the look direction of the sensor. The estimation
of the temporal shift Δt is done by weighting the signal amplitude in each image
with the time t i of this image. The azimuth profiles of the target after masking and
averaging in range are shown in Fig. 15.20. The estimated velocity of the ship imaged
in Fig. 15.18 is 12.2 knots with a dispersion of 1.6 knots when compared to the 11.3
knots available from the AIS information. However, the time lag between the SAR
acquisition and the AIS may allow for the difference.