

266
J. A. J. STOLWI]K
Figure 2. Each of the cylinders is divided up into two or more layers. The
length and radius of each of the concentric rings making up the cylinders
is chosen so that weight, surface area and radial thickness correspond as
closely as possible to anatomical data. The actual values correspond closely
to those given in [2] and the sources upon which the estimates are based are
also given in the same contribution.
It is clear that each of the compartments consists of a combination of
tissues with varying characteristics. In Figure 2, the head consists of two
compartments: the head skin and the head core. The head core consists of
the cranium and its contents. The hand cylinder consists of skin and muscle.
Obviously bone and tendons are considered to be included in the muscle
mass. This lumping means that the heat capacitance and the weight of
hand muscle will be increased by that of the added components. Similar
considerations apply to the other cylinders and their compartments. The
interrelations between the various components are, naturally, also of a
distributed nature. The lumped interrelations, which will be accounted for
in the model, are graphically represented in Figure 3. It will be noticed that
the majority of interrelations are given in broken lines, indicating that they
are under control of the controlling system. The natural consequence is
that the controlling system is capable of modifying the controlled system by
changes in many of the parameters. Since this results in an extremely
complex non-linear system, the formal approaches of control theory are no
longer applicable. It should be pointed out that most of the parameters and
their bounds are available in the literature or their value can be estimated
with reasonable accuracy.
The important values of physical characteristics and basal interrelationships of the compartments of Figures 2 and 3 are given in Table 1. A list of
symbols with their descriptions and dimensions is given in Table 2.
The heat flow rate into or out of any compartment N is given by the
relationship:
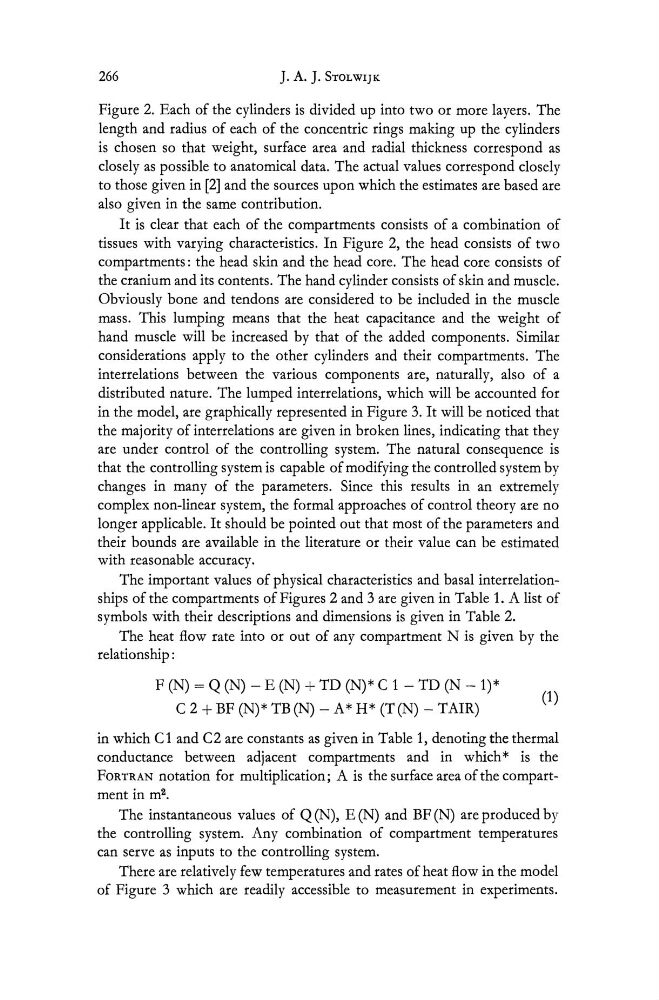
F (N) = Q (N) - E (N) + TD (N)* C 1 - TD (N -1)*
C 2 + BF (N)* TB(N) - A* H* (T(N) - TAIR)
(1 )
in which C 1 and C2 are constants as given in Table 1, denoting the thermal
conductance between adjacent compartments and in which * is the
FORTRAN notation for multiplication; A is the surface area of the compartment in m 2 •
The instantaneous values of Q (N), E (N) and BF (N) are produced by
the controlling system. Any combination of compartment temperatures
can serve as inputs to the controlling system.
There are relatively few temperatures and rates of heat flow in the model
of Figure 3 which are readily accessible to measurement in experiments.