

14
2 1D Models of Ekman Layers
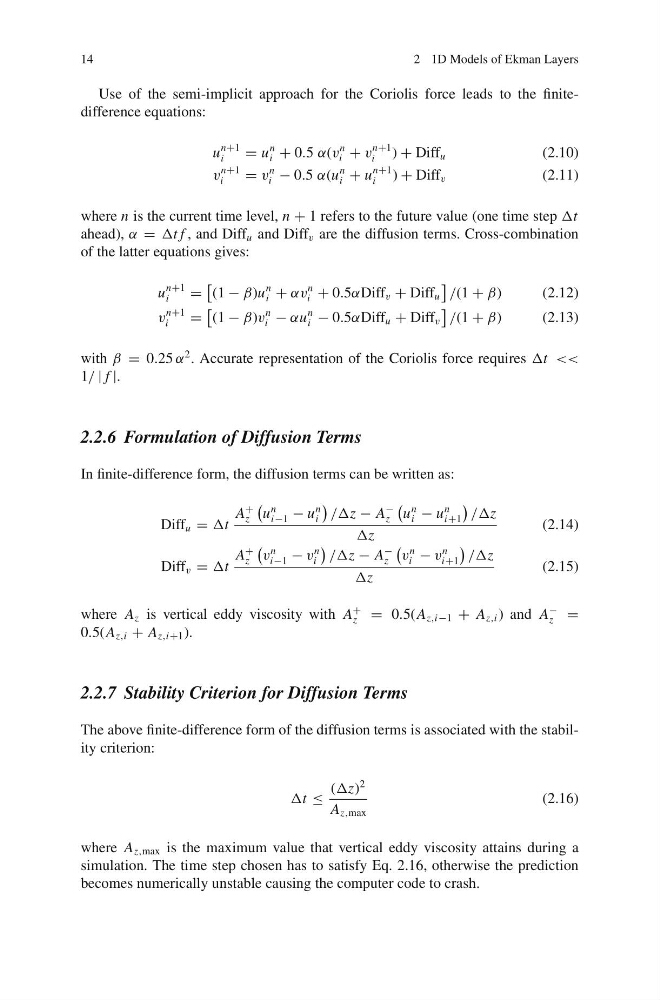
Use of the semi-implicit approach for the Coriolis force leads to the finitedifference equations:
u
n+1
i
= u
n
i + 0.5 α(v
n
i + v
n+1
i
) + Diff u
(2.10)
v
n+1
i
= v
n
i − 0.5 α(u
n
i + u
n+1
i
) + Diff v
(2.11)
where n is the current time level, n + 1 refers to the future value (one time step Δt
ahead), α = Δt f , and Diff u and Diff v are the diffusion terms. Cross-combination
of the latter equations gives:
u
n+1
i
=
(1 − β)u
n
i + αv
n
i + 0.5αDiff v + Diff u
/(1 + β)
(2.12)
v
n+1
i
=
(1 − β)v
n
i − αu
n
i − 0.5αDiff u + Diff v
/(1 + β)
(2.13)
with β = 0.25 α
2 . Accurate representation of the Coriolis force requires Δt <<
1/ | f |.
2.2.6 Formulation of Diffusion Terms
In finite-difference form, the diffusion terms can be written as:
Diff u = Δt
A
+
z
u
n
i−1 − u
n
i
/Δz − A
−
z
u
n
i − u
n
i+1
/Δz
Δz
(2.14)
Diff v = Δt
A
+
z
v
n
i−1 − v
n
i
/Δz − A
−
z
v
n
i − v
n
i+1
/Δz
Δz
(2.15)
where A z is vertical eddy viscosity with A
+
z = 0.5(A z,i−1 + A z,i ) and A
−
z =
0.5(A z,i + A z,i+1 ).
2.2.7 Stability Criterion for Diffusion Terms
The above finite-difference form of the diffusion terms is associated with the stability criterion:
Δt ≤
(Δz)
2
A z,max
(2.16)
where A z,max is the maximum value that vertical eddy viscosity attains during a
simulation. The time step chosen has to satisfy Eq. 2.16, otherwise the prediction
becomes numerically unstable causing the computer code to crash.