

Part A | 10.1
232 Part A Fundamentals
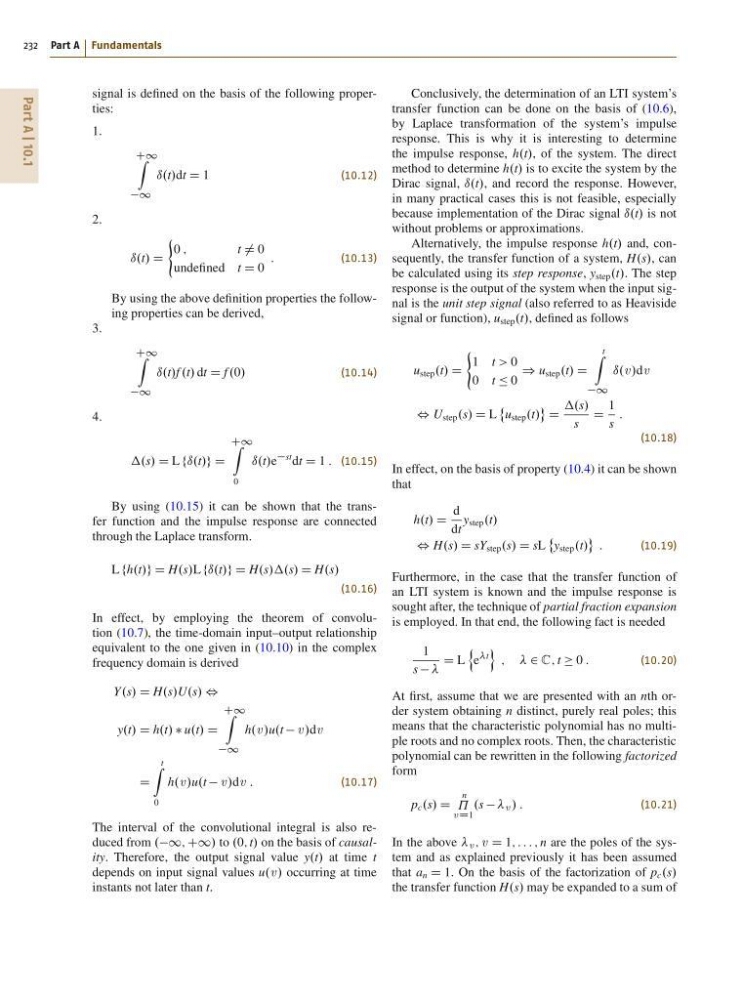
signal is defined on the basis of the following properties:
1.
C1 Z
1
ı.t/dt D 1
(10.12)
2.
ı.t/ D
(
0 ;
t ¤ 0
undefined t D 0
:
(10.13)
By using the above definition properties the following properties can be derived,
3.
C1 Z
1
ı.t/f .t/ dt D f .0/
(10.14)
4.
.s/ D L fı.t/g D
C1 Z
0
ı.t/e
st dt D 1 : (10.15)
By using (10.15) it can be shown that the transfer function and the impulse response are connected
through the Laplace transform.
L fh.t/g D H.s/L fı.t/g D H.s/.s/ D H.s/
(10.16)
In effect, by employing the theorem of convolution (10.7), the time-domain input–output relationship
equivalent to the one given in (10.10) in the complex
frequency domain is derived
Y.s/ D H.s/U.s/ ,
y.t/ D h.t/ u.t/ D
C1 Z
1
h.v /u.t v /dv
D
t
Z
0
h.v /u.t v /dv :
(10.17)
The interval of the convolutional integral is also reduced from .1; C1/ to .0; t/ on the basis of causality. Therefore, the output signal value y.t/ at time t
depends on input signal values u.v / occurring at time
instants not later than t.
Conclusively, the determination of an LTI system’s
transfer function can be done on the basis of (10.6),
by Laplace transformation of the system’s impulse
response. This is why it is interesting to determine
the impulse response, h.t/, of the system. The direct
method to determine h.t/ is to excite the system by the
Dirac signal, ı.t/, and record the response. However,
in many practical cases this is not feasible, especially
because implementation of the Dirac signal ı.t/ is not
without problems or approximations.
Alternatively, the impulse response h.t/ and, consequently, the transfer function of a system, H.s/, can
be calculated using its step response, y step .t/. The step
response is the output of the system when the input signal is the unit step signal (also referred to as Heaviside
signal or function), u step .t/, defined as follows
u step .t/ D
(
1 t > 0
0 t Ä 0
) u step .t/ D
t
Z
1
ı.v /dv
, U step .s/ D L
˚
u step .t/
« D
.s/
s
D
1
s
:
(10.18)
In effect, on the basis of property (10.4) it can be shown
that
h.t/ D
d
dt
y step .t/
, H.s/ D sY step .s/ D sL
˚
y step .t/
« :
(10.19)
Furthermore, in the case that the transfer function of
an LTI system is known and the impulse response is
sought after, the technique of partial fraction expansion
is employed. In that end, the following fact is needed
1
s
D L
n
e
t
o
; ; 2 C; t 0 :
(10.20)
At first, assume that we are presented with an nth order system obtaining n distinct, purely real poles; this
means that the characteristic polynomial has no multiple roots and no complex roots. Then, the characteristic
polynomial can be rewritten in the following factorized
form
p c .s/ D
n
˘
v D1
.s v / :
(10.21)
In the above v ; v D 1; : : : ; n are the poles of the system and as explained previously it has been assumed
that a n D 1. On the basis of the factorization of p c .s/
the transfer function H.s/ may be expanded to a sum of