

Mechanics of Ocean Waves 4.9 Concluding Remarks 97
Part A | 4.9
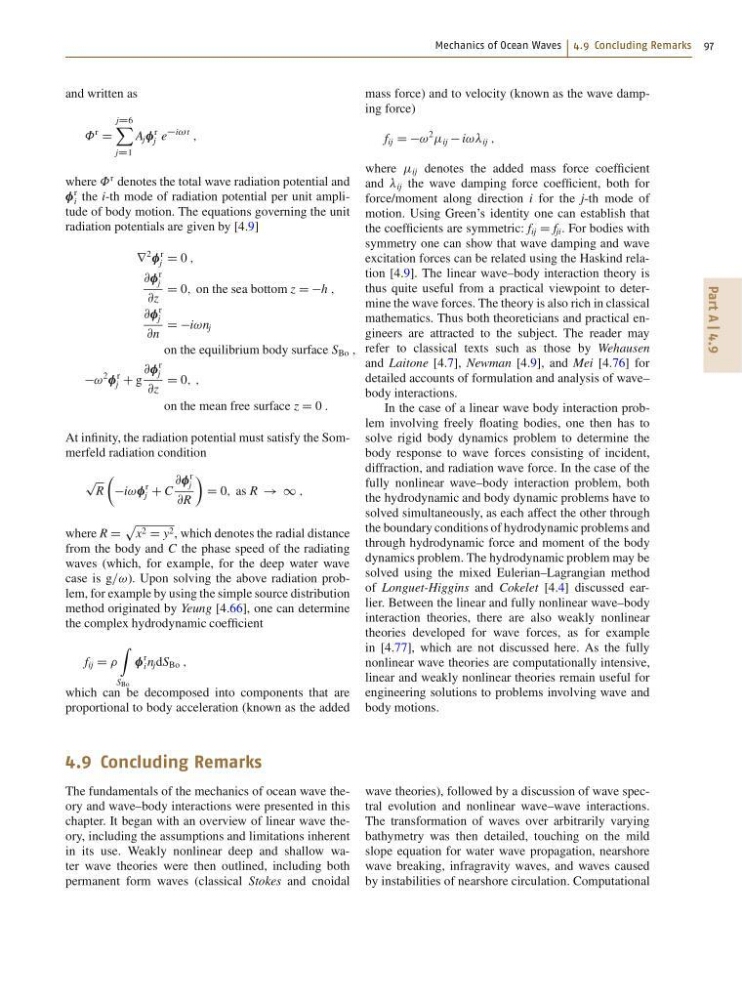
and written as
˚
r
D
jD6
X
jD1
A j
r
j e
i!t
;
where ˚
r denotes the total wave radiation potential and
r
i the i-th mode of radiation potential per unit amplitude of body motion. The equations governing the unit
radiation potentials are given by [4.9]
r
2
r
j D 0 ;
@
r
j
@z
D 0; on the sea bottom z D Dh ;
@
r
j
@n
D Di!n j
on the equilibrium body surface S Bo ;
!
2
r
j C g
@
r
j
@z
D 0; ;
on the mean free surface z D 0 :
At infinity, the radiation potential must satisfy the Sommerfeld radiation condition
p
R
Â
i!
r
j C C
@
r
j
@R
Ã
D 0; as R ! 1 ;
where R D
p
x 2 D y 2 , which denotes the radial distance
from the body and C the phase speed of the radiating
waves (which, for example, for the deep water wave
case is g=!). Upon solving the above radiation problem, for example by using the simple source distribution
method originated by Yeung [4.66], one can determine
the complex hydrodynamic coefficient
f ij D
Z
SBo
r
i n j dS Bo ;
which can be decomposed into components that are
proportional to body acceleration (known as the added
mass force) and to velocity (known as the wave damping force)
f ij D D!
2
ij i!! ij ;
where ij denotes the added mass force coefficient
and ij the wave damping force coefficient, both for
force/moment along direction i for the j-th mode of
motion. Using Green’s identity one can establish that
the coefficients are symmetric: f ij D f ji . For bodies with
symmetry one can show that wave damping and wave
excitation forces can be related using the Haskind relation [4.9]. The linear wave–body interaction theory is
thus quite useful from a practical viewpoint to determine the wave forces. The theory is also rich in classical
mathematics. Thus both theoreticians and practical engineers are attracted to the subject. The reader may
refer to classical texts such as those by Wehausen
and Laitone [4.7], Newman [4.9], and Mei [4.76] for
detailed accounts of formulation and analysis of wave–
body interactions.
In the case of a linear wave body interaction problem involving freely floating bodies, one then has to
solve rigid body dynamics problem to determine the
body response to wave forces consisting of incident,
diffraction, and radiation wave force. In the case of the
fully nonlinear wave–body interaction problem, both
the hydrodynamic and body dynamic problems have to
solved simultaneously, as each affect the other through
the boundary conditions of hydrodynamic problems and
through hydrodynamic force and moment of the body
dynamics problem. The hydrodynamic problem may be
solved using the mixed Eulerian–Lagrangian method
of Longuet-Higgins and Cokelet [4.4] discussed earlier. Between the linear and fully nonlinear wave–body
interaction theories, there are also weakly nonlinear
theories developed for wave forces, as for example
in [4.77], which are not discussed here. As the fully
nonlinear wave theories are computationally intensive,
linear and weakly nonlinear theories remain useful for
engineering solutions to problems involving wave and
body motions.
4.9 Concluding Remarks
The fundamentals of the mechanics of ocean wave theory and wave–body interactions were presented in this
chapter. It began with an overview of linear wave theory, including the assumptions and limitations inherent
in its use. Weakly nonlinear deep and shallow water wave theories were then outlined, including both
permanent form waves (classical Stokes and cnoidal
wave theories), followed by a discussion of wave spectral evolution and nonlinear wave–wave interactions.
The transformation of waves over arbitrarily varying
bathymetry was then detailed, touching on the mild
slope equation for water wave propagation, nearshore
wave breaking, infragravity waves, and waves caused
by instabilities of nearshore circulation. Computational