

228
Ghapter 13: Spatial Patterns: EOFs and GGA
details are unimportant for the "signal". In many cases the noise is not a
nuisance but its statistics are relevant for the understanding of the dynamics
of the signal (see also Chapter 3). Generally the signal has longer scales in
time and space than the noise, and the signal has fewer degrees of freedom
than the noise.
An example is oceanic heat transport - this signal is low frequent and large
in spatial scale. The extratropical storms are in this context noise, since the
individual storms do not matter, but the ensemble of the storms, or the storm
track is of utmost importance as this ensemble controls the energy exchange
at the interface of atmosphere and ocean. Thus, for some oceanographers
the individual storms are noise. For a synoptic meteorologist an individual
storm is the object of interest, and thus the signal. But to understand an
individual storm does not require the detailed knowledge of each cloud within
the storm, so the clouds are noise in this context.
The purpose of this chapter is to discuss how the "signal" subspace may be
represented by characteristic patterns. The specification of such characteristic patterns can be done in various ways, ranging from purely subjectively
defined patterns, patterns with favorable geometrie properties like a powerful
representation of prescribed spatial scales (such as spherical harmonics) to
patterns which are defined to optimize statistical parameters. Empirical Orthogonal Functions (EOFs) are optimal in representing variancej Canonical
Correlation Patterns (CCPs) maximize the correlation between two simultaneously observed fields)j others such as PIPs and POPs (see Chapter 15)
satisfy certain dynamical constraints.
In this contribution we first represent the general idea of projecting large
fields on a few "guess patterns" (Section 13.2). Then EOFs are defined as
those 'patterns which are most powerful in explaining variance of a random
field X (Section 13.3). In Section 13.4 the Canonical Correlation Analysis of
two simultaneously observed random fields (X, Y) is introduced.
13.2 Expansion into a Few Guess Patterns
13.2.1 Guess Patterns, Expansion Coefficients
and Explained Variance
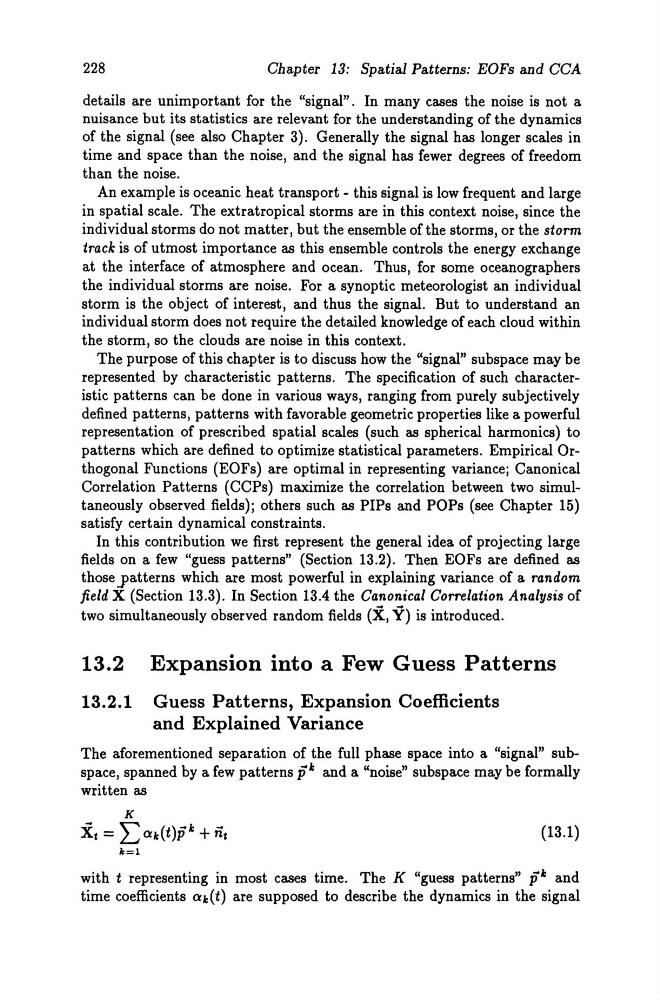
The aforementioned separation of the full phase space into a "signal" subspace, spanned by a few patterns pI; and a "noise" subspace may be formally
written as
K
Xt = L O:k(t)iI; + fit
(13.1)
with t representing in most cases time. The K "guess patterns" pk and
time coefficients O:k(t) are supposed to describe the dynamics in the signal