

270
9. Turbulent Flows
have also been used. In general, for a given order of accuracy, Runge-Kutta
methods require more computation per time step. Despite this, they are preferred because, for a given time step, the errors they produce are much smaller
than those of the competing methods. Thus, in practice, they allow a larger
time step for the same accuracy and this more than compensates for thesincreased amount of computation. The Crank-Nicolson method is often applied
to the terms that must be treated implicitly.
A difficulty with time-advance methods is that ones of accuracy higher
than first order require storage of data at more than one time step (including
intermediate time steps) and, as the amount of data contained in a single
velocity field is large, the demand for storage may exceed what is available
even with the large memories in modern computers. This puts a premium on
designing and using methods which demand relatively little storage. As an
example of a method of this kind, Leonard and Wray (1982) presented a third
order Runge-Kutta method which requires less storage than the standard
Runge-Kutta method of that accuracy.
A further issue of importance in DNS is the need to handle a wide range
of length scales; this requires a change in the way one thinks about discretization methods. The most common descriptor of the accuracy of a spatial discretization method is its order, a number that describes the rate a t which the
discretization error decreases when the grid size is reduced. Some discussion
of why this is not the appropriate measure of quality was given in Chap. 3;
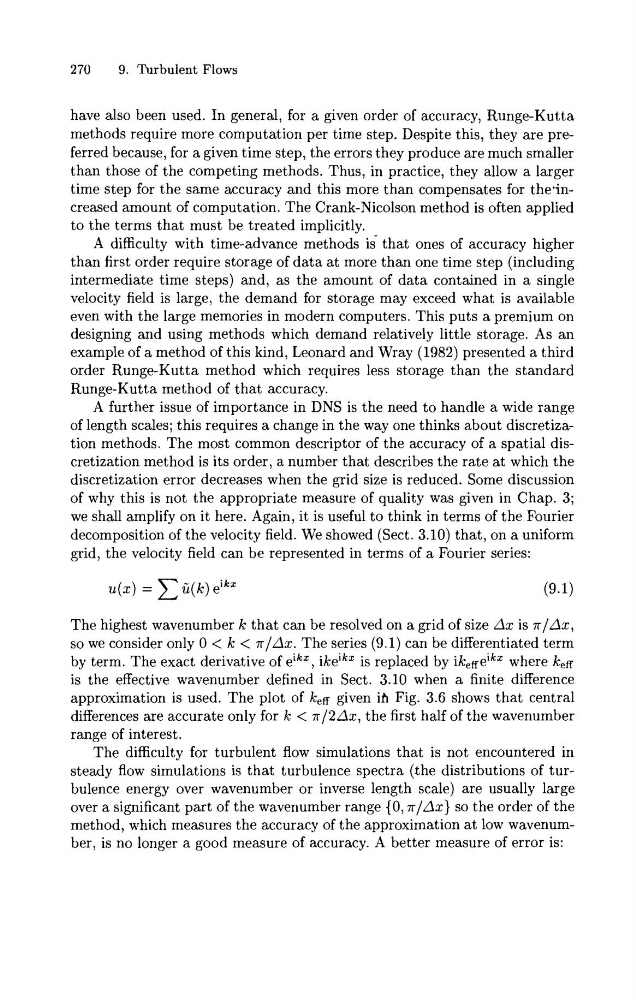
we shall amplify on it here. Again, it is useful to think in terms of the Fourier
decomposition of the velocity field. We showed (Sect. 3.10) that, on a uniform
grid, the velocity field can be represented in terms of a Fourier series:
The highest wavenumber k that can be resolved on a grid of size Ax is r / A x ,
so we consider only 0 < k < r / A x . The series (9.1) can be differentiated term
by term. The exact derivative of eikx, ikeikx is replaced by ikeffeikx where keff
is the effective wavenumber defined in Sect. 3.10 when a finite difference
approximation is used. The plot of keff given ih Fig. 3.6 shows that central
differences are accurate only for k < ~ / 2 A x ,
the first half of the wavenumber
range of interest.
The difficulty for turbulent flow simulations that is not encountered in
steady flow simulations is that turbulence spectra (the distributions of turbulence energy over wavenumber or inverse length scale) are usually large
over a significant part of the wavenumber range (0, r / A x ) so the order of the
method, which measures the accuracy of the approximation a t low wavenumber, is no longer a good measure of accuracy. A better measure of error is: