

6.3 Application to the Generic Transport Equation
151
The coefficients AE and Aw are the same as in case of implicit Euler scheme,
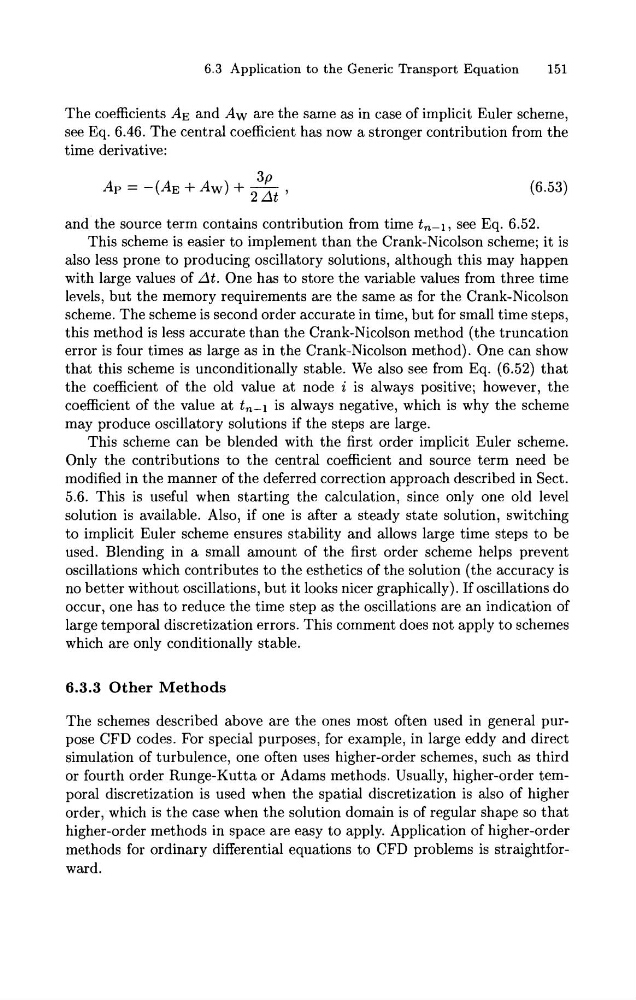
see Eq. 6.46. The central coefficient has now a stronger contribution from the
time derivative:
and the source term contains contribution from time tn-l, see Eq. 6.52.
This scheme is easier to implement than the Crank-Nicolson scheme; it is
also less prone to producing oscillatory solutions, although this may happen
with large values of At. One has to store the variable values from three time
levels, but the memory requirements are the same as for the Crank-Nicolson
scheme. The scheme is second order accurate in time, but for small time steps,
this method is less accurate than the Crank-Nicolson method (the truncation
error is four times as large as in the Crank-Nicolson method). One can show
that this scheme is unconditionally stable. We also see from Eq. (6.52) that
the coefficient of the old value a t node i is always positive; however, the
coefficient of the value a t tn-l is always negative, which is why the scheme
may produce oscillatory solutions if the steps are large.
This scheme can be blended with the first order implicit Euler scheme.
Only the contributions to the central coefficient and source term need be
modified in the manner of the deferred correction approach described in Sect.
5.6. This is useful when starting the calculation, since only one old level
solution is available. Also, if one is after a steady state solution, switching
to implicit Euler scheme ensures stability and allows large time steps t o be
used. Blending in a small amount of the first order scheme helps prevent
oscillations which contributes to the esthetics of the solution (the accuracy is
no better without oscillations, but it looks nicer graphically). If oscillations do
occur, one has t o reduce the time step as the oscillations are an indication of
large temporal discretization errors. This comment does not apply t o schemes
which are only conditionally stable.
6.3.3 Other Methods
The schemes described above are the ones most often used in general purpose CFD codes. For special purposes, for example, in large eddy and direct
simulation of turbulence, one often uses higher-order schemes, such as third
or fourth order Runge-Kutta or Adams methods. Usually, higher-order temporal discretization is used when the spatial discretization is also of higher
order, which is the case when the solution domain is of regular shape so that
higher-order methods in space are easy to apply. Application of higher-order
methods for ordinary differential equations to CFD problems is straightforward.