

362
M.A. Chapman et al.
and
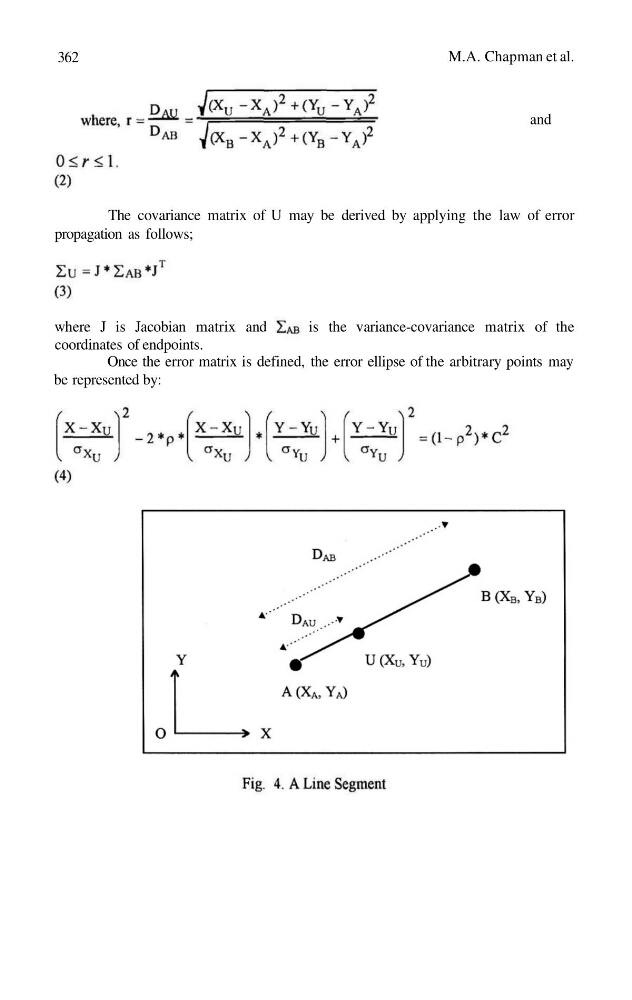
The covariance matrix of U may be derived by applying the law of error
propagation as follows;
where J is Jacobian matrix and
is the variance-covariance matrix of the
coordinates of endpoints.
Once the error matrix is defined, the error ellipse of the arbitrary points may
be represented by: