

An Outline of Lagrangian Stochastic Dispersion Models
221
It is worth noticing that a suffi cient number of particles should be released at each
time step in order to obtain meaningful concentrations since too few particles
give a patchy and incorrect representation of the concentration distribution. On
the other hand, releasing too many particles requires a too long computing time.
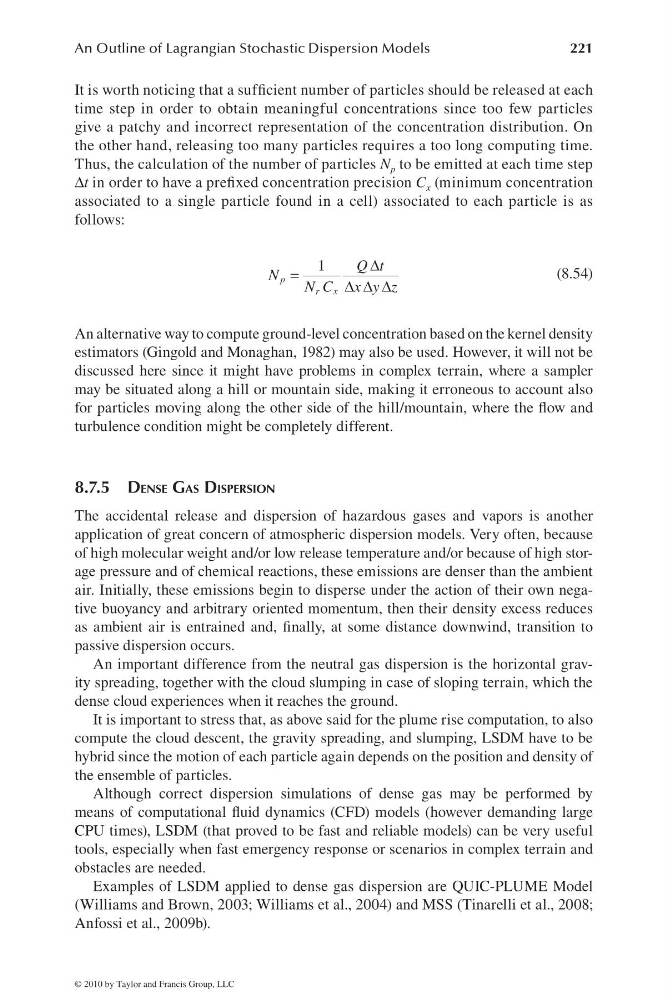
Thus, the calculation of the number of particles N p to be emitted at each time step
Δt in order to have a prefi xed concentration precision C x (minimum concentration
associated to a single particle found in a cell) associated to each particle is as
follows:
1
p
r x
Q t
N
N C x y z
Δ
=
Δ Δ Δ
(8.54)
An alternative way to compute ground-level concentration based on the kernel density
estimators (Gingold and Monaghan, 1982) may also be used. However, it will not be
discussed here since it might have problems in complex terrain, where a sampler
may be situated along a hill or mountain side, making it erroneous to account also
for particles moving along the other side of the hill/mountain, where the fl ow and
turbulence condition might be completely different.
8.7.5 DENSE GAS DISPERSION
The accidental release and dispersion of hazardous gases and vapors is another
application of great concern of atmospheric dispersion models. Very often, because
of high molecular weight and/or low release temperature and/or because of high storage pressure and of chemical reactions, these emissions are denser than the ambient
air. Initially, these emissions begin to disperse under the action of their own negative buoyancy and arbitrary oriented momentum, then their density excess reduces
as ambient air is entrained and, fi nally, at some distance downwind, transition to
passive dispersion occurs.
An important difference from the neutral gas dispersion is the horizontal gravity spreading, together with the cloud slumping in case of sloping terrain, which the
dense cloud experiences when it reaches the ground.
It is important to stress that, as above said for the plume rise computation, to also
compute the cloud descent, the gravity spreading, and slumping, LSDM have to be
hybrid since the motion of each particle again depends on the position and density of
the ensemble of particles.
Although correct dispersion simulations of dense gas may be performed by
means of computational fl uid dynamics (CFD) models (however demanding large
CPU times), LSDM (that proved to be fast and reliable models) can be very useful
tools, especially when fast emergency response or scenarios in complex terrain and
obstacles are needed.
Examples of LSDM applied to dense gas dispersion are QUIC-PLUME Model
(Williams and Brown, 2003; Williams et al., 2004) and MSS (Tinarelli et al., 2008;
Anfossi et al., 2009b).
© 2010 by Taylor and Francis Group, LLC