

An Outline of Lagrangian Stochastic Dispersion Models
209
1
A B
+ =
(8.19a)
0
A
B
Aw Bw
+
=
(8.19b)
2
2
2
2
(
)
(
)
A
A
B
B
A w
B w
w
+ σ +
+ σ =
(8.19c)
3
2
3
2
3
(
3
)
(
3
)
A
A A
B
B B
A w
w
B w
w
w
+
σ +
+
σ =
(8.19d)
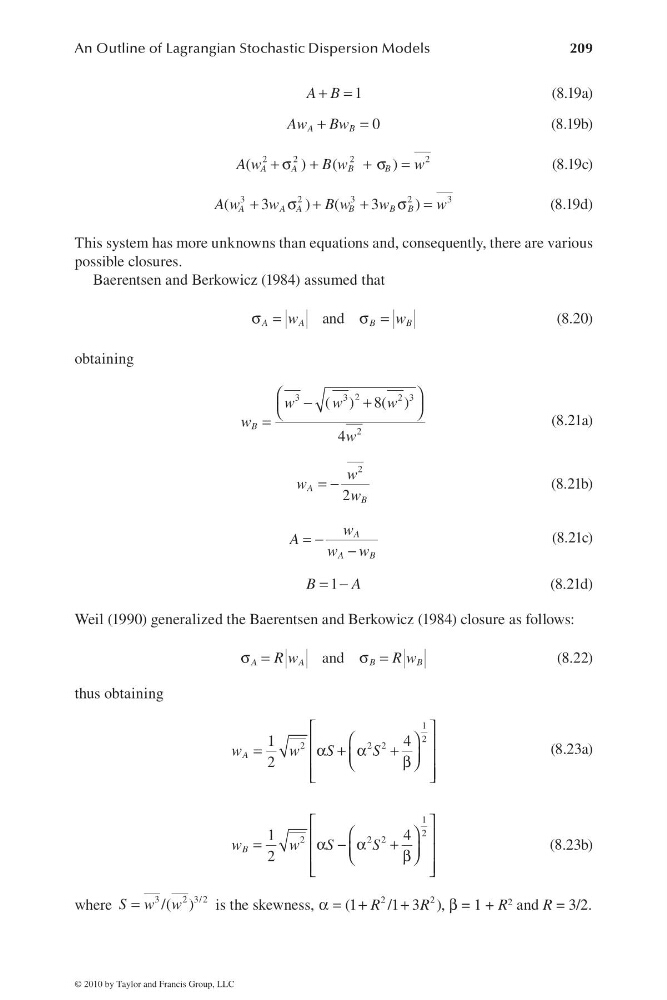
This system has more unknowns than equations and, consequently, there are various
possible closures.
Baerentsen and Berkowicz (1984) assumed that
and
A
A
B
B
w
w
σ =
σ =
(8.20)
obtaining
2
3
3
23
2
( ) 8( )
4
B
w
w
w
w
w
⎛
⎞
−
+
⎜
⎟
⎝
⎠
=
(8.21a)
2
2
A
B
w
w
w
= −
(8.21b)
A
A
B
w
A
w w
= −
−
(8.21c)
1
B
A
= −
(8.21d)
Weil (1990) generalized the Baerentsen and Berkowicz (1984) closure as follows:
and
A
A
B
B
R w
R w
σ =
σ =
(8.22)
thus obtaining
1
2
2
22
1
4
2
A
w
w
S
S
⎡
⎤
⎛
⎞
⎢
⎥
=
α + α
+
⎜
⎟
⎢
⎥
β
⎝
⎠
⎢
⎥
⎣
⎦
(8.23a)
1
2
2
22
1
4
2
B
w
w
S
S
⎡
⎤
⎛
⎞
⎢
⎥
=
α − α
+
⎜
⎟
⎢
⎥
β
⎝
⎠
⎢
⎥
⎣
⎦
(8.23b)
where =
3
2 3 /2
/( )
S w w
is the skewness,
2
2
(1
/1 3 )
R
R
α = +
+
, β = 1 + R 2 and R = 3/2.
© 2010 by Taylor and Francis Group, LLC