

228
IX – Multivariate Differential and Integral Calculus
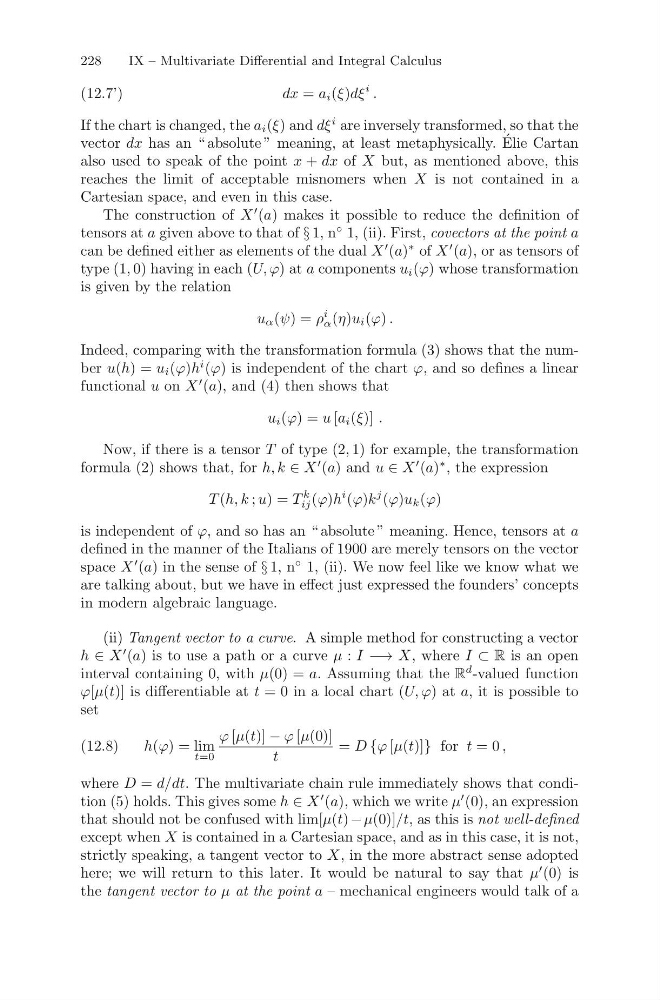
dx = a i (ξ)dξ
i .
(12.7’)
If the chart is changed, the a i (ξ) and dξ
i are inversely transformed, so that the
vector dx has an “ absolute ” meaning, at least metaphysically. ´
Elie Cartan
also used to speak of the point x + dx of X but, as mentioned above, this
reaches the limit of acceptable misnomers when X is not contained in a
Cartesian space, and even in this case.
The construction of X
(a) makes it possible to reduce the definition of
tensors at a given above to that of § 1, n
◦ 1, (ii). First, covectors at the point a
can be defined either as elements of the dual X
(a)
∗ of X
(a), or as tensors of
type (1, 0) having in each (U, ϕ) at a components u i (ϕ) whose transformation
is given by the relation
u α (ψ) = ρ
i
α (η)u i (ϕ) .
Indeed, comparing with the transformation formula (3) shows that the number u(h) = u i (ϕ)h
i (ϕ) is independent of the chart ϕ, and so defines a linear
functional u on X
(a), and (4) then shows that
u i (ϕ) = u [a i (ξ)] .
Now, if there is a tensor T of type (2, 1) for example, the transformation
formula (2) shows that, for h, k ∈ X
(a) and u ∈ X
(a)
∗ , the expression
T (h, k ; u) = T
k
ij (ϕ)h
i (ϕ)k
j (ϕ)u k (ϕ)
is independent of ϕ, and so has an “ absolute ” meaning. Hence, tensors at a
defined in the manner of the Italians of 1900 are merely tensors on the vector
space X
(a) in the sense of § 1, n
◦ 1, (ii). We now feel like we know what we
are talking about, but we have in effect just expressed the founders’ concepts
in modern algebraic language.
(ii) Tangent vector to a curve. A simple method for constructing a vector
h ∈ X
(a) is to use a path or a curve μ : I −→ X, where I ⊂ R is an open
interval containing 0, with μ(0) = a. Assuming that the R
d -valued function
ϕ[μ(t)] is differentiable at t = 0 in a local chart (U, ϕ) at a, it is possible to
set
h(ϕ) = lim
t=0
ϕ [μ(t)] − ϕ [μ(0)]
t
= D {ϕ [μ(t)]} for t = 0 ,
(12.8)
where D = d/dt. The multivariate chain rule immediately shows that condition (5) holds. This gives some h ∈ X
(a), which we write μ
(0), an expression
that should not be confused with lim[μ(t) − μ(0)]/t, as this is not well-defined
except when X is contained in a Cartesian space, and as in this case, it is not,
strictly speaking, a tangent vector to X, in the more abstract sense adopted
here; we will return to this later. It would be natural to say that μ
(0) is
the tangent vector to μ at the point a – mechanical engineers would talk of a