

§ 4. Differential Manifolds
227
where (e i ) is the canonical basis of R
d ,
h(ψ) = θ
(ξ)h(ϕ) .
(12.5)
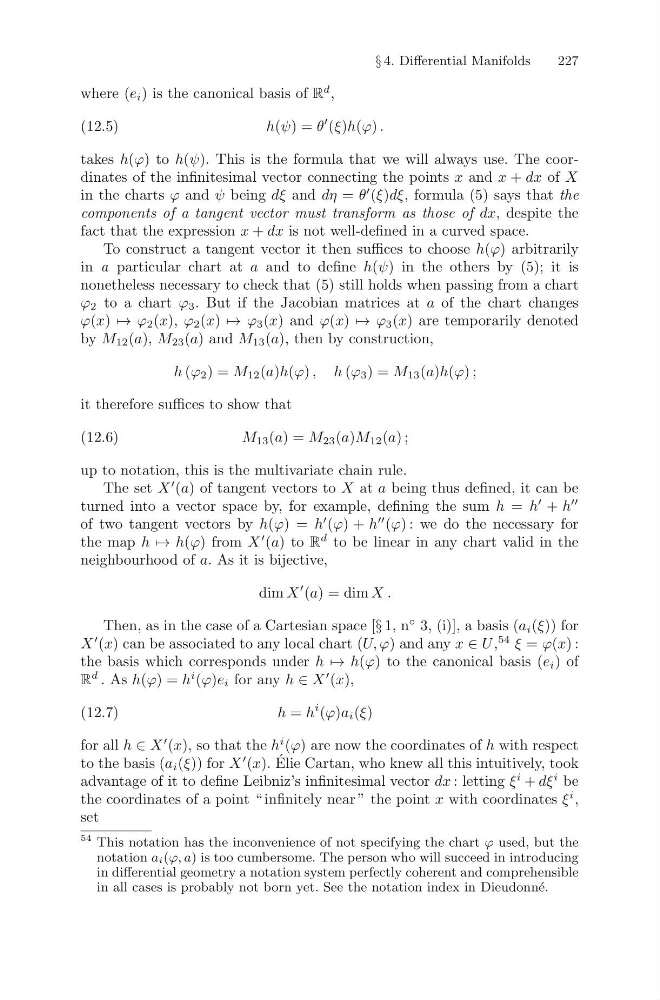
takes h(ϕ) to h(ψ). This is the formula that we will always use. The coordinates of the infinitesimal vector connecting the points x and x + dx of X
in the charts ϕ and ψ being dξ and dη = θ
(ξ)dξ, formula (5) says that the
components of a tangent vector must transform as those of dx, despite the
fact that the expression x + dx is not well-defined in a curved space.
To construct a tangent vector it then suffices to choose h(ϕ) arbitrarily
in a particular chart at a and to define h(ψ) in the others by (5); it is
nonetheless necessary to check that (5) still holds when passing from a chart
ϕ 2 to a chart ϕ 3 . But if the Jacobian matrices at a of the chart changes
ϕ(x) → ϕ 2 (x), ϕ 2 (x) → ϕ 3 (x) and ϕ(x) → ϕ 3 (x) are temporarily denoted
by M 12 (a), M 23 (a) and M 13 (a), then by construction,
h (ϕ 2 ) = M 12 (a)h(ϕ) , h(ϕ 3 ) = M 13 (a)h(ϕ) ;
it therefore suffices to show that
M 13 (a) = M 23 (a)M 12 (a) ;
(12.6)
up to notation, this is the multivariate chain rule.
The set X
(a) of tangent vectors to X at a being thus defined, it can be
turned into a vector space by, for example, defining the sum h = h
+ h
of two tangent vectors by h(ϕ) = h
(ϕ) + h
(ϕ) : we do the necessary for
the map h → h(ϕ) from X
(a) to R
d to be linear in any chart valid in the
neighbourhood of a. As it is bijective,
dim X
(a) = dim X .
Then, as in the case of a Cartesian space [§ 1, n
◦ 3, (i)], a basis (a i (ξ)) for
X
(x) can be associated to any local chart (U, ϕ) and any x ∈ U ,
54 ξ = ϕ(x) :
the basis which corresponds under h → h(ϕ) to the canonical basis (e i ) of
R
d . As h(ϕ) = h
i (ϕ)e i for any h ∈ X
(x),
h = h
i (ϕ)a i (ξ)
(12.7)
for all h ∈ X
(x), so that the h
i (ϕ) are now the coordinates of h with respect
to the basis (a i (ξ)) for X
(x). ´
Elie Cartan, who knew all this intuitively, took
advantage of it to define Leibniz’s infinitesimal vector dx : letting ξ
i + dξ
i be
the coordinates of a point “ infinitely near ” the point x with coordinates ξ
i ,
set
54 This notation has the inconvenience of not specifying the chart ϕ used, but the
notation ai(ϕ, a) is too cumbersome. The person who will succeed in introducing
in differential geometry a notation system perfectly coherent and comprehensible
in all cases is probably not born yet. See the notation index in Dieudonn´ e.