

248 8 “Ellipsoid-of-revolution to tangential plane”
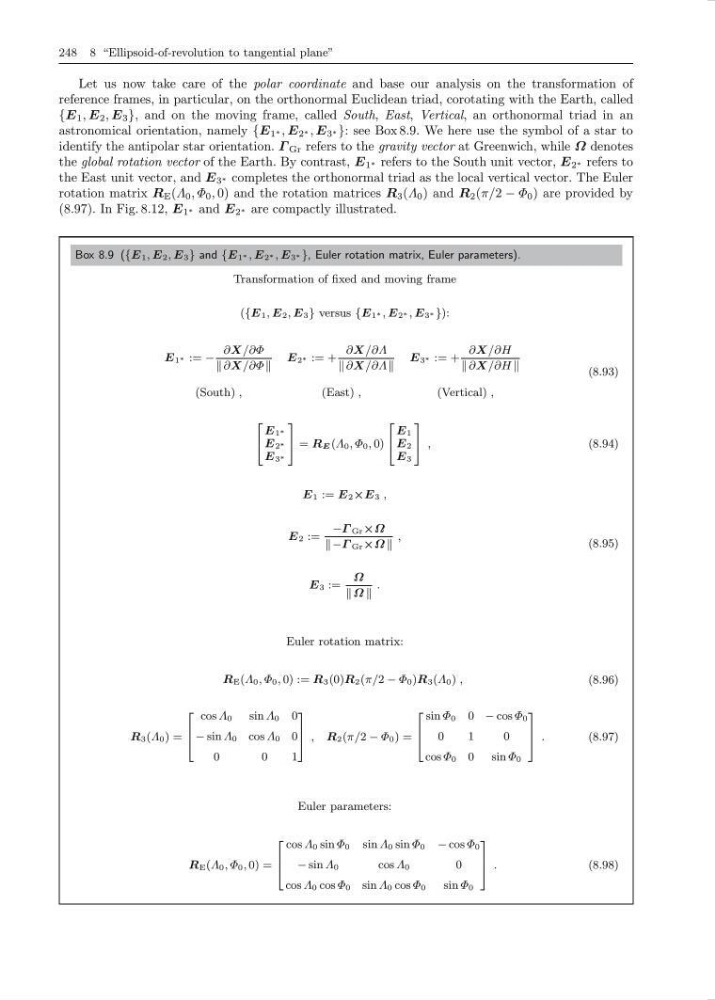
Let us now take care of the polar coordinate and base our analysis on the transformation of
reference frames, in particular, on the orthonormal Euclidean triad, corotating with the Earth, called
{E 1 , E 2 , E 3 }, and on the moving frame, called South, East, Vertical, an orthonormal triad in an
astronomical orientation, namely {E 1 ∗ , E 2 ∗ , E 3 ∗ }: see Box 8.9. We here use the symbol of a star to
identify the antipolar star orientation. Γ Gr refers to the gravity vector at Greenwich, while Ω denotes
the global rotation vector of the Earth. By contrast, E 1 ∗ refers to the South unit vector, E 2 ∗ refers to
the East unit vector, and E 3 ∗ completes the orthonormal triad as the local vertical vector. The Euler
rotation matrix R E (Λ 0 , Φ 0 , 0) and the rotation matrices R 3 (Λ 0 ) and R 2 (π/2 − Φ 0 ) are provided by
(8.97). In Fig. 8.12, E 1 ∗ and E 2 ∗ are compactly illustrated.
Box 8.9 ({E 1 , E 2 , E 3 } and {E 1 ∗ , E 2 ∗ , E 3 ∗ }, Euler rotation matrix, Euler parameters).
Transformation of fixed and moving frame
({E 1 , E 2 , E 3 } versus {E 1 ∗ , E 2 ∗ , E 3 ∗ }):
E 1 ∗ := −
∂X/∂Φ
∂X /∂Φ
(South) ,
E 2 ∗ := +
∂X /∂Λ
∂X /∂Λ
(East) ,
E 3 ∗ := +
∂X /∂H
∂X /∂H
(Vertical) ,
(8.93)
2
4
E 1 ∗
E 2 ∗
E 3 ∗
3
5 = R E (Λ 0 , Φ 0 , 0)
2
4
E 1
E 2
E 3
3
5 ,
(8.94)
E 1 := E 2 ×E 3 ,
E 2 :=
−Γ Gr ×Ω
−Γ Gr ×Ω
,
E 3 :=
Ω
Ω
.
(8.95)
Euler rotation matrix:
R E (Λ 0 , Φ 0 , 0) := R 3 (0)R 2 (π/2 − Φ 0 )R 3 (Λ 0 ) ,
(8.96)
R 3 (Λ 0 ) =
2
6
4
cos Λ 0 sin Λ 0 0
− sin Λ 0 cos Λ 0 0
0
0
1
3
7
5 , R 2 (π/2 − Φ 0 ) =
2
6
4
sin Φ 0 0 − cos Φ 0
0
1
0
cos Φ 0 0 sinΦ 0
3
7
5 .
(8.97)
Euler parameters:
R E (Λ 0 , Φ 0 , 0) =
2
6
4
cos Λ 0 sin Φ 0 sin Λ 0 sin Φ 0 − cos Φ 0
− sin Λ 0
cos Λ 0
0
cos Λ 0 cos Φ 0 sin Λ 0 cos Φ 0
sin Φ 0
3
7
5 .
(8.98)