

3-3 The oblique frame of reference of the sphere 135
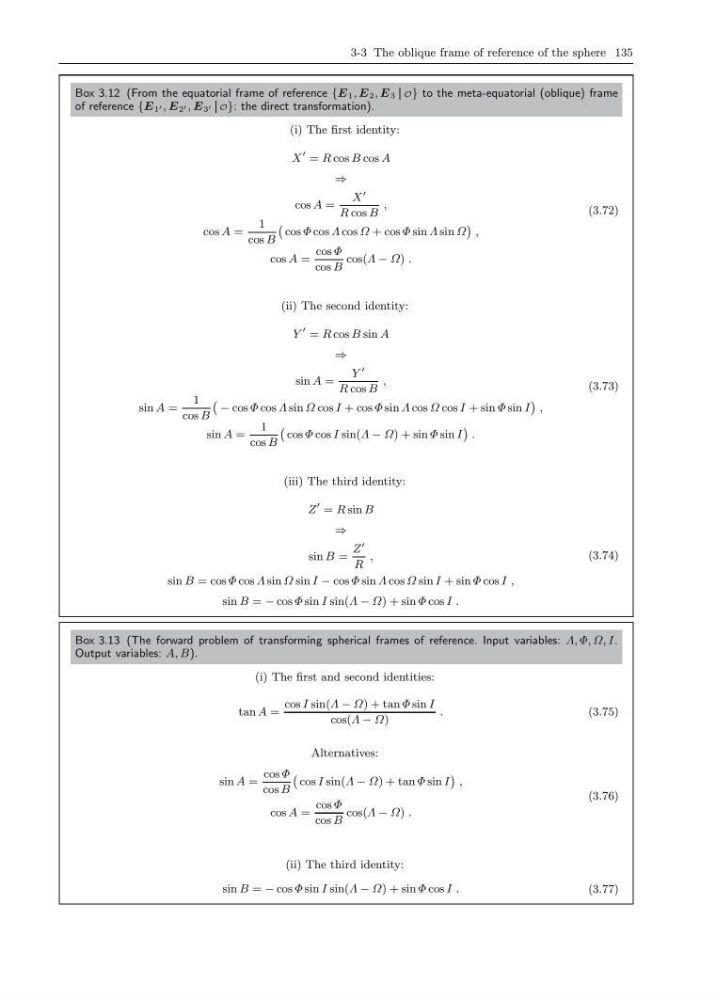
Box 3.12 (From the equatorial frame of reference {E 1 , E 2 , E 3 O} to the meta-equatorial (oblique) frame
of reference {E 1 , E 2 , E 3 O}: the direct transformation).
(i) The first identity:
X
= R cos B cos A
⇒
cos A =
X
R cos B
,
cos A =
1
cos B
`
cos Φ cos Λ cos Ω + cos Φ sin Λ sin Ω
´
,
cos A =
cos Φ
cos B
cos(Λ − Ω) .
(3.72)
(ii) The second identity:
Y
= R cos B sin A
⇒
sin A =
Y
R cos B
,
sin A =
1
cos B
` − cos Φ cos Λ sin Ω cos I + cos Φ sin Λ cos Ω cos I + sin Φ sin I
´
,
sin A =
1
cos B
`
cos Φ cos I sin(Λ − Ω) + sin Φ sin I
´
.
(3.73)
(iii) The third identity:
Z
= R sin B
⇒
sin B =
Z
R
,
sin B = cos Φ cos Λ sin Ω sin I − cos Φ sin Λ cos Ω sin I + sin Φ cos I ,
sin B = − cos Φ sin I sin(Λ − Ω) + sin Φ cos I .
(3.74)
Box 3.13 (The forward problem of transforming spherical frames of reference. Input variables: Λ, Φ, Ω, I.
Output variables: A, B).
(i) The first and second identities:
tan A =
cos I sin(Λ − Ω) + tan Φ sin I
cos(Λ − Ω)
.
(3.75)
Alternatives:
sin A =
cos Φ
cos B
`
cos I sin(Λ − Ω) + tan Φ sin I
´
,
cos A =
cos Φ
cos B
cos(Λ − Ω) .
(3.76)
(ii) The third identity:
sin B = − cos Φ sin I sin(Λ − Ω) + sin Φ cos I .
(3.77)