

116 3 Coordinates
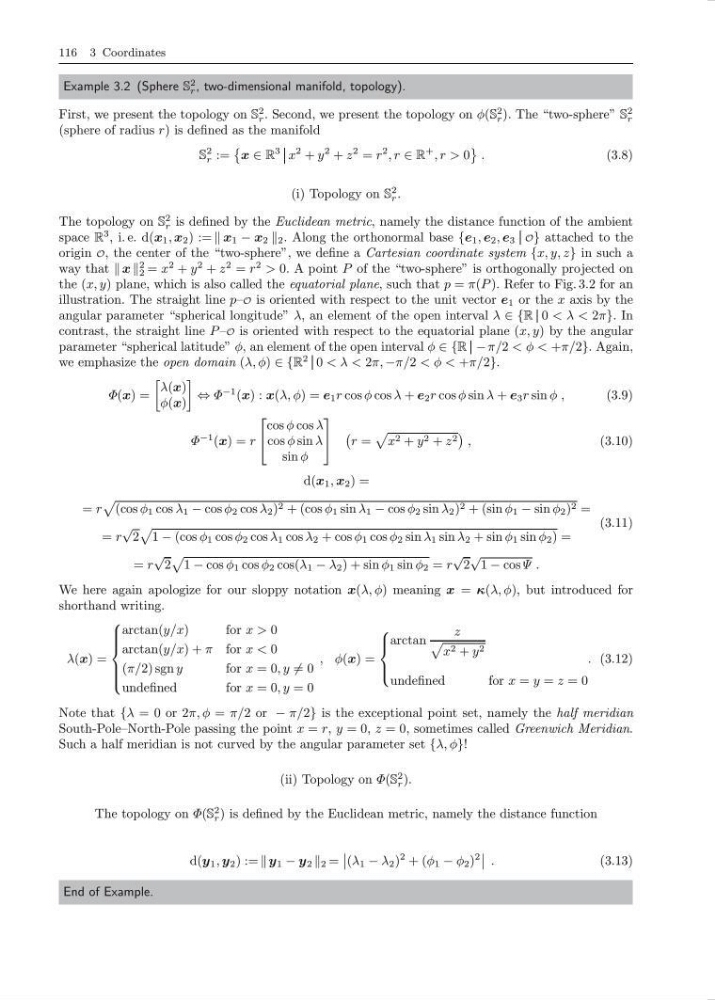
Example 3.2 (Sphere S
2
r , two-dimensional manifold, topology).
First, we present the topology on S
2
r . Second, we present the topology on φ(S
2
r ). The “two-sphere” S
2
r
(sphere of radius r) is defined as the manifold
S
2
r :=
x ∈ R
3 x
2 + y
2 + z
2 = r
2 , r ∈ R
+ , r > 0
.
(3.8)
(i) Topology on S
2
r .
The topology on S
2
r is defined by the Euclidean metric, namely the distance function of the ambient
space R
3 , i. e. d(x 1 , x 2 ) := x 1 − x 2 2 . Along the orthonormal base {e 1 , e 2 , e 3 O} attached to the
origin O, the center of the “two-sphere”, we define a Cartesian coordinate system {x, y, z} in such a
way that x
2
2 = x
2 + y
2 + z
2 = r
2 > 0. A point P of the “two-sphere” is orthogonally projected on
the (x, y) plane, which is also called the equatorial plane, such that p = π(P ). Refer to Fig. 3.2 for an
illustration. The straight line p–O is oriented with respect to the unit vector e 1 or the x axis by the
angular parameter “spherical longitude” λ, an element of the open interval λ ∈ {R 0 < λ < 2π}. In
contrast, the straight line P –O is oriented with respect to the equatorial plane (x, y) by the angular
parameter “spherical latitude” φ, an element of the open interval φ ∈ {R − π/2 < φ < +π/2}. Again,
we emphasize the open domain (λ, φ) ∈ {R
2 0 < λ < 2π, −π/2 < φ < +π/2}.
Φ(x) =
λ(x)
φ(x)
⇔ Φ
−1 (x) : x(λ, φ) = e 1 r cos φ cos λ + e 2 r cos φ sin λ + e 3 r sin φ ,
(3.9)
Φ
−1 (x) = r
⎡
⎣
cos φ cos λ
cos φ sin λ
sin φ
⎤
⎦
r =
x 2 + y 2 + z 2
,
(3.10)
d(x 1 , x 2 ) =
= r
(cos φ 1 cos λ 1 − cos φ 2 cos λ 2 ) 2 + (cos φ 1 sin λ 1 − cos φ 2 sin λ 2 ) 2 + (sin φ 1 − sin φ 2 ) 2 =
= r
√
2
1 − (cos φ 1 cos φ 2 cos λ 1 cos λ 2 + cos φ 1 cos φ 2 sin λ 1 sin λ 2 + sin φ 1 sin φ 2 ) =
= r
√
2
1 − cos φ 1 cos φ 2 cos(λ 1 − λ 2 ) + sin φ 1 sin φ 2 = r
√
2
√
1 − cos Ψ .
(3.11)
We here again apologize for our sloppy notation x(λ, φ) meaning x = κ(λ, φ), but introduced for
shorthand writing.
λ(x) =
⎧
⎪ ⎪ ⎪ ⎨
⎪ ⎪ ⎪ ⎩
arctan(y/x)
forx > 0
arctan(y/x) + π for x < 0
(π/2) sgn y
for x = 0, y = 0
undefined
for x = 0, y = 0
, φ(x) =
⎧
⎪ ⎨
⎪ ⎩
arctan
z
x 2 + y 2
undefined
for x = y = z = 0
. (3.12)
Note that {λ = 0 or 2π, φ = π/2 or − π/2} is the exceptional point set, namely the half meridian
South-Pole–North-Pole passing the point x = r, y = 0, z = 0, sometimes called Greenwich Meridian.
Such a half meridian is not curved by the angular parameter set {λ, φ}!
(ii) Topology on Φ(S
2
r ).
The topology on Φ(S
2
r ) is defined by the Euclidean metric, namely the distance function
d(y 1 , y 2 ) := y 1 − y 2 2 =
(λ 1 − λ 2 )
2 + (φ 1 − φ 2 )
2
.
(3.13)
End of Example.