

306
7 Lagrangian and Hamiltonian Mechanics
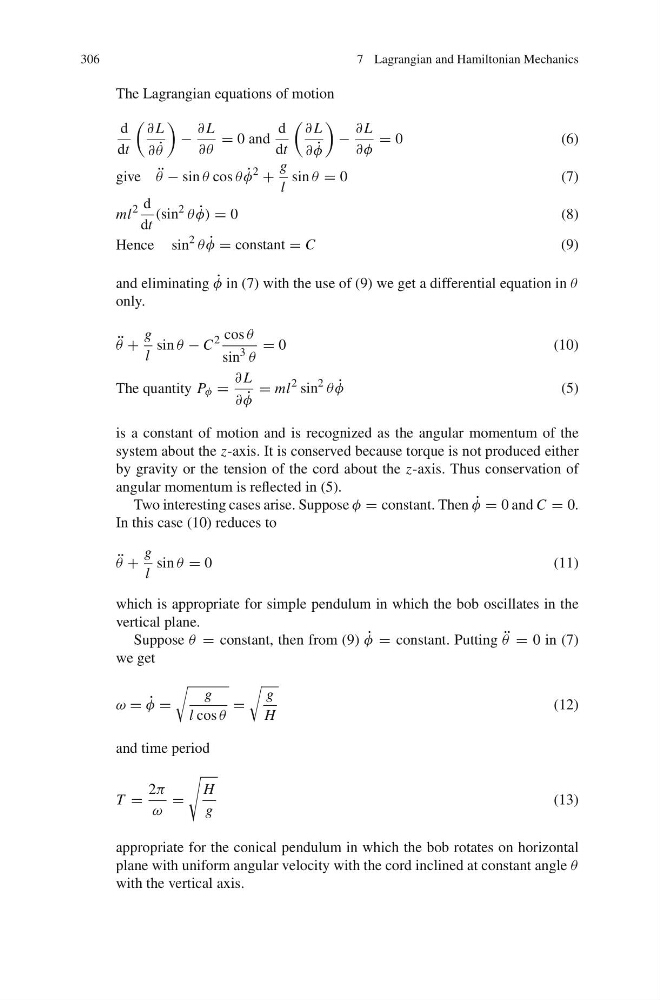
The Lagrangian equations of motion
d
dt
∂ L
∂ ˙
θ
−
∂ L
∂θ
= 0 and
d
dt
∂ L
∂ ˙
φ
−
∂ L
∂φ
= 0
( 6 )
give ¨
θ − sin θ cos θ ˙
φ
2
+
g
l
sin θ = 0
( 7 )
ml
2 d
dt
(sin
2
θ ˙
φ) = 0
( 8 )
Hence sin
2
θ ˙
φ = constant = C
(9)
and eliminating ˙
φ in (7) with the use of (9) we get a differential equation in θ
only.
¨
θ +
g
l
sin θ − C
2 cos θ
sin
3
θ
= 0
(10)
The quantity P φ =
∂ L
∂ ˙
φ
= ml
2 sin
2
θ ˙
φ
(5)
is a constant of motion and is recognized as the angular momentum of the
system about the z-axis. It is conserved because torque is not produced either
by gravity or the tension of the cord about the z-axis. Thus conservation of
angular momentum is reflected in (5).
Two interesting cases arise. Suppose φ = constant. Then ˙
φ = 0 and C = 0.
In this case (10) reduces to
¨
θ +
g
l
sin θ = 0
(11)
which is appropriate for simple pendulum in which the bob oscillates in the
vertical plane.
Suppose θ = constant, then from (9) ˙
φ = constant. Putting ¨
θ = 0 in (7)
we get
ω = ˙
φ =
g
l cos θ
=
g
H
(12)
and time period
T =
2π
ω
=
H
g
(13)
appropriate for the conical pendulum in which the bob rotates on horizontal
plane with uniform angular velocity with the cord inclined at constant angle θ
with the vertical axis.