

298
7 Lagrangian and Hamiltonian Mechanics
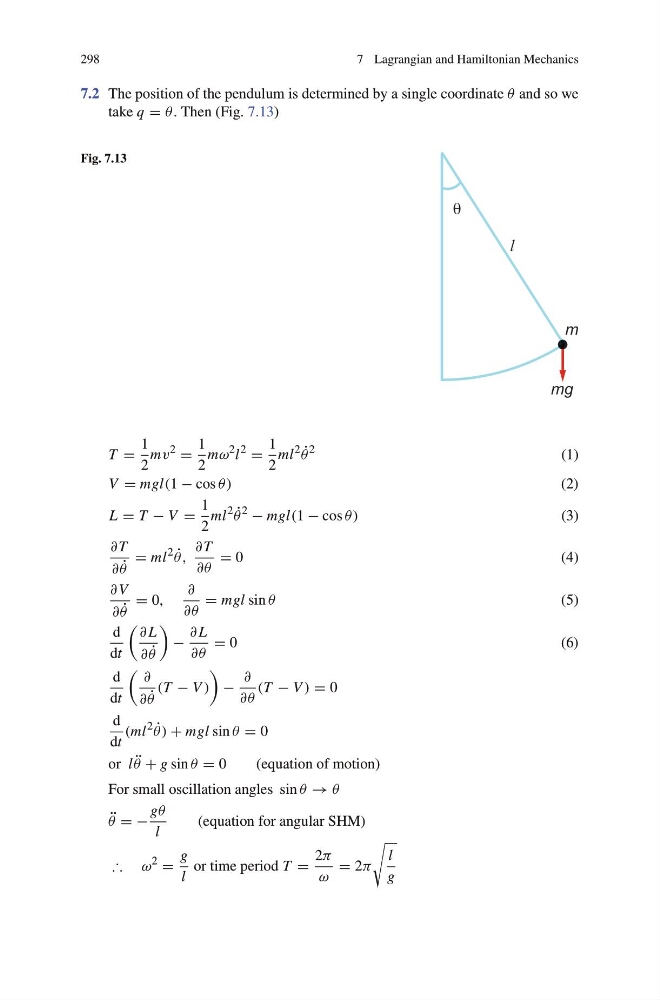
7.2 The position of the pendulum is determined by a single coordinate θ and so we
take q = θ . Then (Fig. 7.13)
Fig. 7.13
T =
1
2
mv
2
=
1
2
mω
2 l
2
=
1
2
ml
2 ˙
θ
2
(1)
V = mgl(1 − cos θ)
(2)
L = T − V =
1
2
ml
2 ˙
θ
2
− mgl(1 − cos θ)
(3)
∂ T
∂ ˙
θ
= ml
2 ˙
θ,
∂ T
∂θ
= 0
( 4 )
∂ V
∂ ˙
θ
= 0,
∂
∂θ
= mgl sin θ
(5)
d
dt
∂ L
∂ ˙
θ
−
∂ L
∂θ
= 0
( 6 )
d
dt
∂
∂ ˙
θ
(T − V )
−
∂
∂θ
(T − V ) = 0
d
dt
(ml
2 ˙
θ) + mgl sin θ = 0
or l ¨
θ + g sin θ = 0
(equation of motion)
For small oscillation angles sin θ → θ
¨
θ = −
gθ
l
(equation for angular SHM)
∴ ω
2
=
g
l
or time period T =
2π
ω
= 2π
l
g