

182
4 Rotational Dynamics
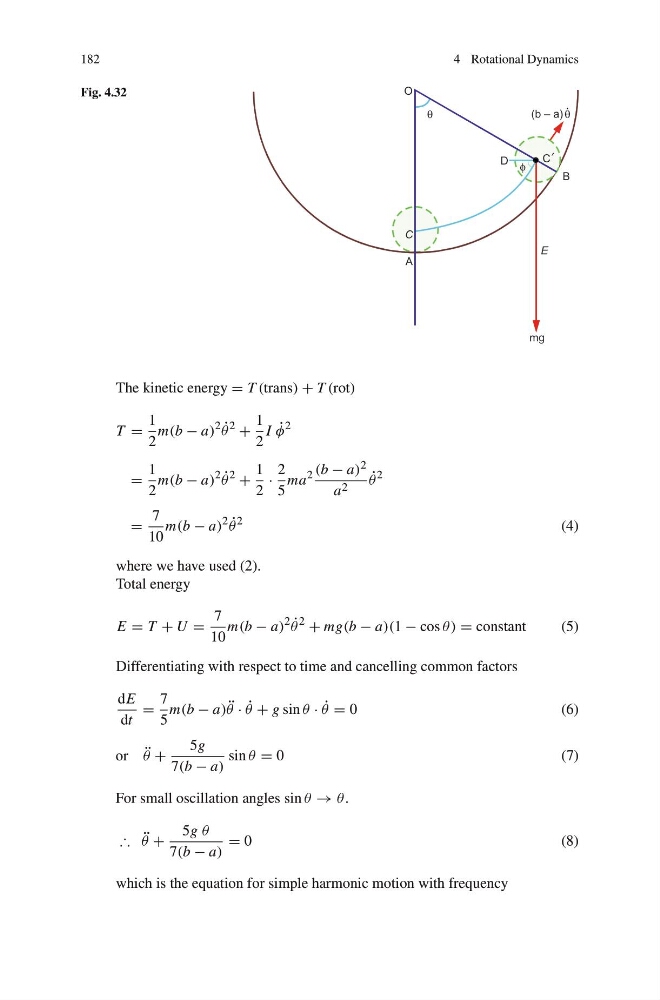
Fig. 4.32
The kinetic energy = T (trans) + T (rot)
T =
1
2
m(b − a)
2 ˙
θ
2
+
1
2
I ˙
φ
2
=
1
2
m(b − a)
2 ˙
θ
2
+
1
2
·
2
5
ma
2 (b − a) 2
a 2
˙
θ
2
=
7
10
m(b − a)
2 ˙
θ
2
(4)
where we have used (2).
Total energy
E = T + U =
7
10
m(b − a)
2 ˙
θ
2
+ mg(b − a)(1 − cos θ) = constant
(5)
Differentiating with respect to time and cancelling common factors
dE
dt
=
7
5
m(b − a) ¨
θ · ˙
θ + g sin θ · ˙
θ = 0
( 6 )
or ¨
θ +
5g
7(b − a)
sin θ = 0
( 7 )
For small oscillation angles sin θ → θ .
∴ ¨
θ +
5g θ
7(b − a)
= 0
( 8 )
which is the equation for simple harmonic motion with frequency