

152
4 Rotational Dynamics
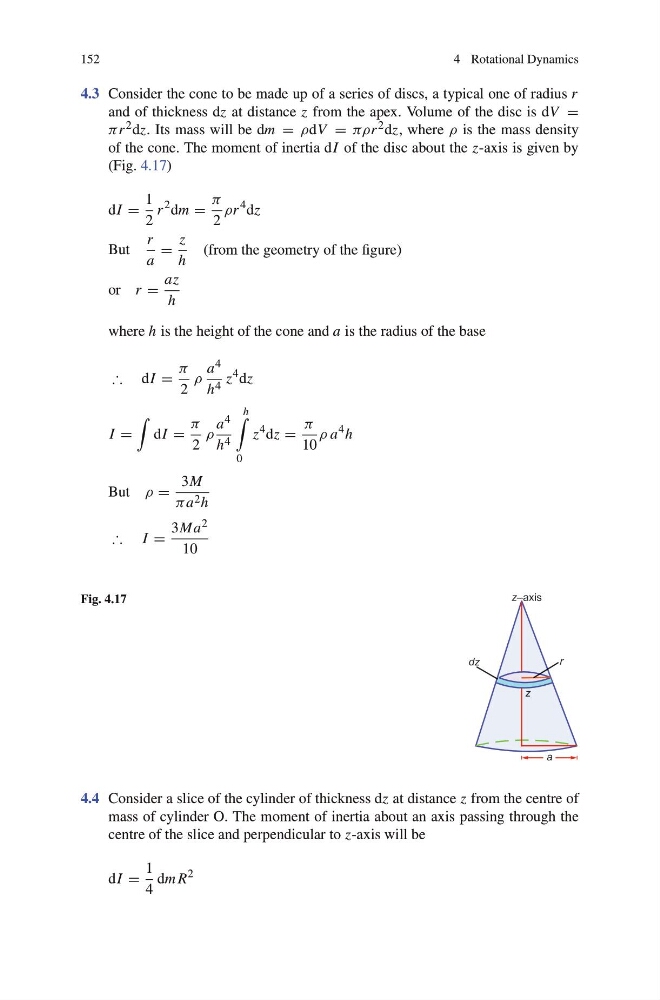
4.3 Consider the cone to be made up of a series of discs, a typical one of radius r
and of thickness dz at distance z from the apex. Volume of the disc is dV =
πr 2 dz. Its mass will be dm = ρdV = πρr 2 dz, where ρ is the mass density
of the cone. The moment of inertia dI of the disc about the z-axis is given by
(Fig. 4.17)
dI =
1
2
r
2 dm =
π
2
ρr
4 dz
But
r
a
=
z
h
(from the geometry of the figure)
or r =
az
h
where h is the height of the cone and a is the radius of the base
∴ dI =
π
2
ρ
a 4
h 4 z
4 dz
I =
dI =
π
2
ρ
a 4
h 4
h
0
z
4 dz =
π
10
ρ a
4 h
But ρ =
3M
πa 2 h
∴ I =
3Ma 2
10
Fig. 4.17
4.4 Consider a slice of the cylinder of thickness dz at distance z from the centre of
mass of cylinder O. The moment of inertia about an axis passing through the
centre of the slice and perpendicular to z-axis will be
dI =
1
4
dm R
2