

Additional examples, video, and practice available at WileyPLUS
336
CHAPTE R 12 EQU I LI B R I U M AN D E L ASTICITY
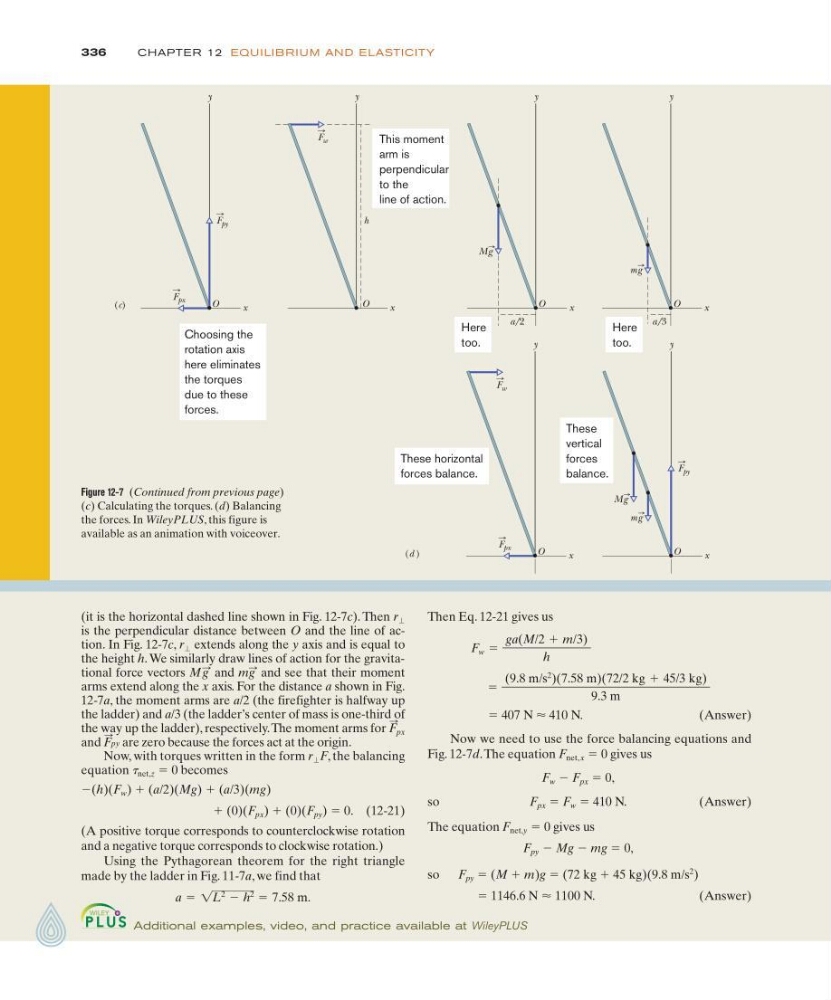
Figure 12-7 (Continued from previous page)
(c) Calculating the torques. (d) Balancing
the forces. In WileyPLUS, this figure is
available as an animation with voiceover.
(it is the horizontal dashed line shown in Fig. 12-7c). Then r Ќ
is the perpendicular distance between O and the line of action. In Fig. 12-7c, r Ќ extends along the y axis and is equal to
the height h. We similarly draw lines of action for the gravitational force vectors
and
and see that their moment
arms extend along the x axis. For the distance a shown in Fig.
12-7a, the moment arms are a/2 (the firefighter is halfway up
the ladder) and a/3 (the ladder’s center of mass is one-third of
the way up the ladder), respectively.The moment arms for
and
are zero because the forces act at the origin.
Fpy
:
F px
:
mg
:
Mg
:
Then Eq. 12-21 gives us
ϭ 407 N Ϸ 410 N.
(Answer)
Now we need to use the force balancing equations and
Fig. 12-7d.The equation F net, x ϭ 0 gives us
F w Ϫ F px ϭ 0,
so
F px ϭ F w ϭ 410 N.
(Answer)
The equation F net,y ϭ 0 gives us
F py Ϫ Mg Ϫ mg ϭ 0,
so F py ϭ (M ϩ m)g ϭ (72 kg ϩ 45 kg)(9.8 m/s
2
)
ϭ 1146.6 N Ϸ 1100 N.
(Answer)
ϭ
(9.8 m/s
2
)(7.58 m)(72/2 kg ϩ 45/3 kg)
9.3 m
F w ϭ
ga(M/2 ϩ m/3)
h
Now, with torques written in the form r Ќ F, the balancing
equation t net,z ϭ 0 becomes
Ϫ(h)(F w ) ϩ (a/2)(Mg) ϩ (a/3)(mg)
ϩ (0)(F px ) ϩ (0)(F py ) ϭ 0. (12-21)
(A positive torque corresponds to counterclockwise rotation
and a negative torque corresponds to clockwise rotation.)
Using the Pythagorean theorem for the right triangle
made by the ladder in Fig. 11-7a, we find that
.
a ϭ 1L
2 Ϫ h
2 ϭ 7.58 m
y
x
mg
Mg
O
F py
y
x
O
F px
F w
(c)
(d )
y
x
O
F px
F py
y
x
O
h
F w
y
x
Mg
O
a/2
a/3
y
x
mg
O
Choosing the
rotation axis
here eliminates
the torques
due to these
forces.
This moment
arm is
perpendicular
to the
line of action.
These horizontal
forces balance.
These
vertical
forces
balance.
Here
too.
Here
too.