

326
5 Numerical Models for Pebble-Bed Heat Transfer
Thus, only A is an independent parameter, which is the maximum of solid volume
fraction for a single particle, and A =
π
√
18
for the densest packing of mono-sized
particles.
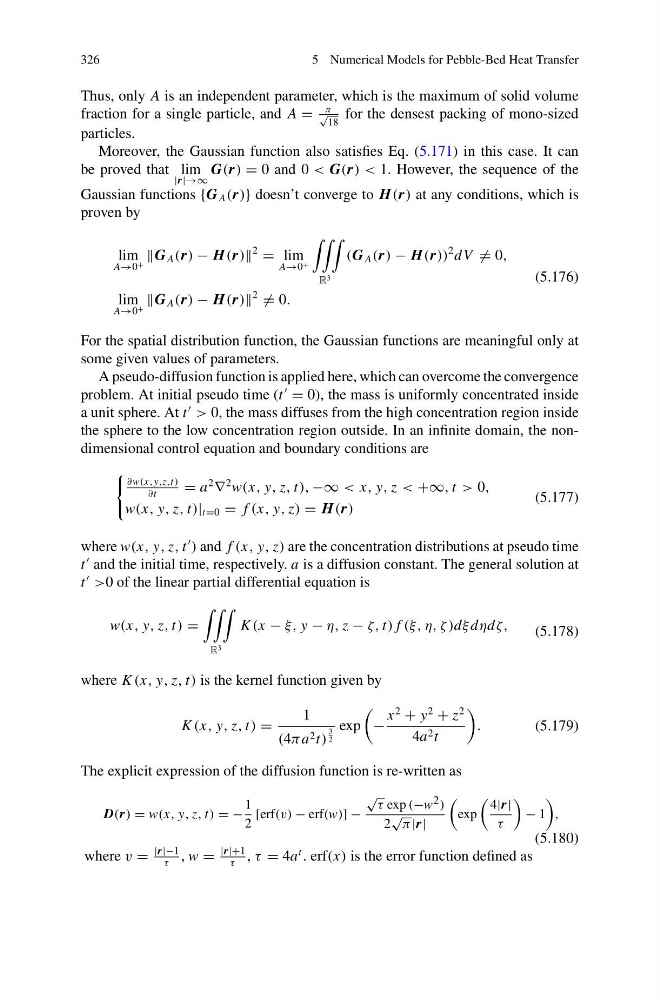
Moreover, the Gaussian function also satisfies Eq. (5.171) in this case. It can
be proved that lim
|r|→∞
G(r) = 0 and 0 < G(r) < 1. However, the sequence of the
Gaussian functions {G A (r)} doesn’t converge to H(r) at any conditions, which is
proven by
lim
A→0 +
G A (r) − H(r)
2
= lim
A→0 +
R 3
(G A (r) − H(r))
2 dV = 0,
lim
A→0 +
G A (r) − H(r)
2
= 0.
(5.176)
For the spatial distribution function, the Gaussian functions are meaningful only at
some given values of parameters.
A pseudo-diffusion function is applied here, which can overcome the convergence
problem. At initial pseudo time (t
= 0), the mass is uniformly concentrated inside
a unit sphere. At t
> 0, the mass diffuses from the high concentration region inside
the sphere to the low concentration region outside. In an infinite domain, the nondimensional control equation and boundary conditions are
∂w(x,y,z,t)
∂t
= a
2
∇
2 w(x, y, z, t), −∞ < x, y, z < +∞, t > 0,
w(x, y, z, t)| t=0 = f (x, y, z) = H(r)
(5.177)
where w(x, y, z, t
) and f (x, y, z) are the concentration distributions at pseudo time
t
and the initial time, respectively. a is a diffusion constant. The general solution at
t
>0 of the linear partial differential equation is
w(x, y, z, t) =
R 3
K (x − ξ, y − η, z − ζ, t) f (ξ, η, ζ )dξ dηdζ,
(5.178)
where K (x, y, z, t) is the kernel function given by
K (x, y, z, t) =
1
(4πa 2 t)
3
2
exp
−
x
2
+ y
2
+ z
2
4a 2 t
.
(5.179)
The explicit expression of the diffusion function is re-written as
D(r) = w(x, y, z, t) = −
1
2
[erf(v) − erf(w)] −
√
τ exp (−w 2 )
2
√ π|r|
exp
4|r|
τ
− 1
,
(5.180)
where v =
|r|−1
τ
, w =
|r|+1
τ
, τ = 4a
t . erf(x) is the error function defined as