

310
5 Numerical Models for Pebble-Bed Heat Transfer
5.4.1 Governing Equations
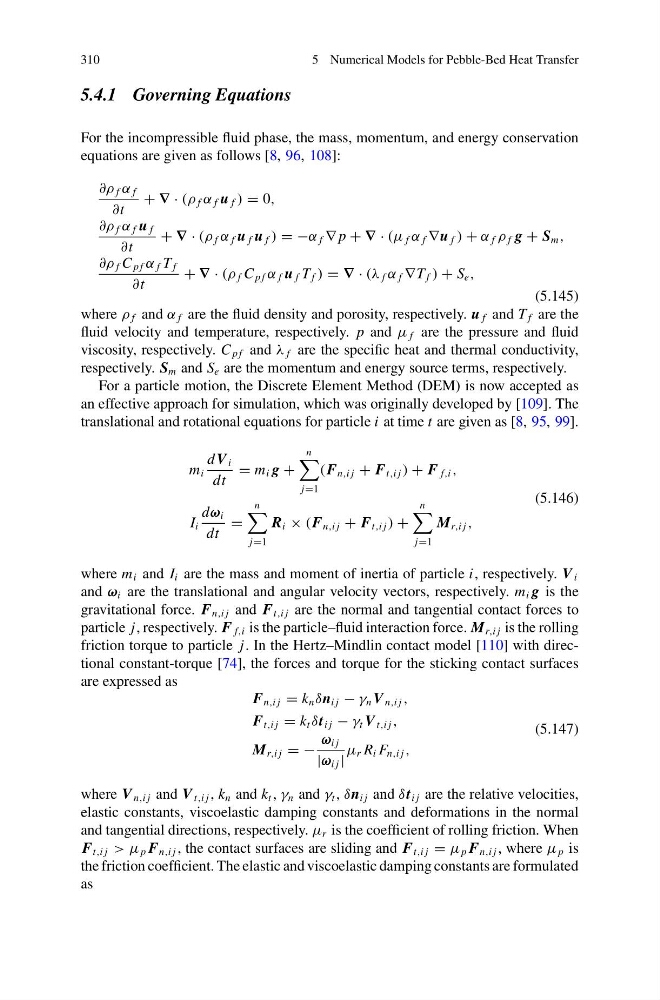
For the incompressible fluid phase, the mass, momentum, and energy conservation
equations are given as follows [8, 96, 108]:
∂ρ f α f
∂t
+ ∇ · (ρ f α f u f ) = 0,
∂ρ f α f u f
∂t
+ ∇ · (ρ f α f u f u f ) = −α f ∇ p + ∇ · (μ f α f ∇u f ) + α f ρ f g + S m ,
∂ρ f C p f α f T f
∂t
+ ∇ · (ρ f C p f α f u f T f ) = ∇ · (λ f α f ∇T f ) + S e ,
(5.145)
where ρ f and α f are the fluid density and porosity, respectively. u f and T f are the
fluid velocity and temperature, respectively. p and μ f are the pressure and fluid
viscosity, respectively. C p f and λ f are the specific heat and thermal conductivity,
respectively. S m and S e are the momentum and energy source terms, respectively.
For a particle motion, the Discrete Element Method (DEM) is now accepted as
an effective approach for simulation, which was originally developed by [109]. The
translational and rotational equations for particle i at time t are given as [8, 95, 99].
m i
d V i
dt
= m i g +
n
j=1
(F n,i j + F t,i j ) + F f,i ,
I i
dω i
dt
=
n
j=1
R i × (F n,i j + F t,i j ) +
n
j=1
M r,i j ,
(5.146)
where m i and I i are the mass and moment of inertia of particle i, respectively. V i
and ω i are the translational and angular velocity vectors, respectively. m i g is the
gravitational force. F n,i j and F t,i j are the normal and tangential contact forces to
particle j, respectively. F f,i is the particle–fluid interaction force. M r,i j is the rolling
friction torque to particle j. In the Hertz–Mindlin contact model [110] with directional constant-torque [74], the forces and torque for the sticking contact surfaces
are expressed as
F n,i j = k n δn i j − γ n V n,i j ,
F t,i j = k t δt i j − γ t V t,i j ,
M r,i j = −
ω i j
|ω i j |
μ r R i F n,i j ,
(5.147)
where V n,i j and V t,i j , k n and k t , γ n and γ t , δn i j and δt i j are the relative velocities,
elastic constants, viscoelastic damping constants and deformations in the normal
and tangential directions, respectively. μ r is the coefficient of rolling friction. When
F t,i j > μ p F n,i j , the contact surfaces are sliding and F t,i j = μ p F n,i j , where μ p is
the friction coefficient. The elastic and viscoelastic damping constants are formulated
as