

1.2 A Bilinear Conjugate-Gradient Inversion Algorithm Using Volume-Integrals
9
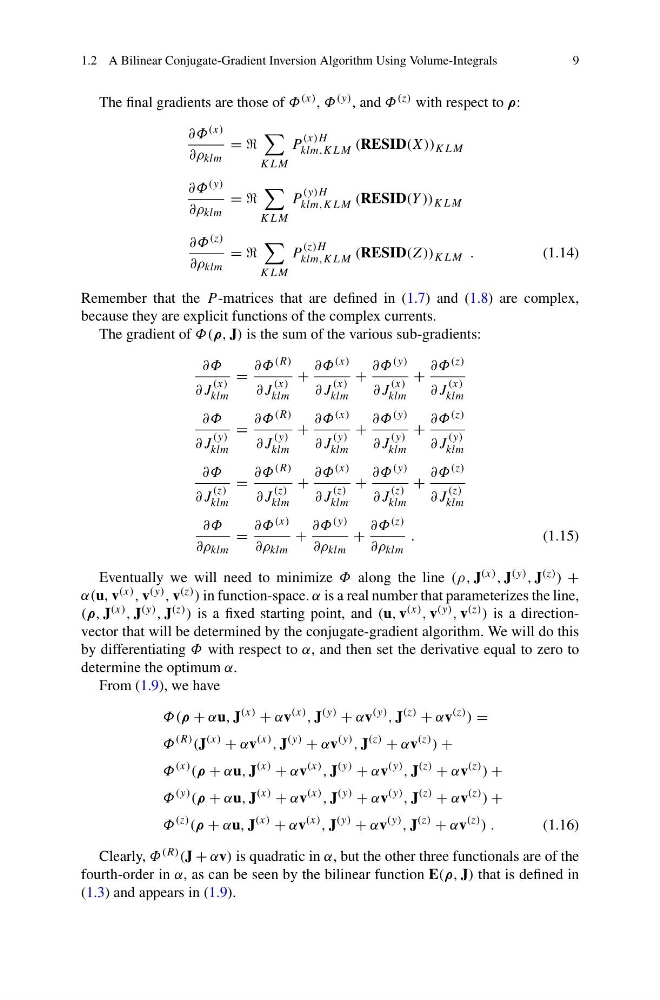
The final gradients are those of Φ (x) , Φ (y) , and Φ (z) with respect to ρ:
∂Φ (x)
∂ρ klm
= =
KLM
P
(x)H
klm,KLM (RESID(X)) KLM
∂Φ (y)
∂ρ klm
= =
KLM
P
(y)H
klm,KLM (RESID(Y )) KLM
∂Φ (z)
∂ρ klm
= =
KLM
P
(z)H
klm,KLM (RESID(Z)) KLM .
(1.14)
Remember that the P -matrices that are defined in (1.7) and (1.8) are complex,
because they are explicit functions of the complex currents.
The gradient of Φ(ρ, J) is the sum of the various sub-gradients:
∂Φ
∂J
(x)
klm
=
∂Φ (R)
∂J
(x)
klm
+
∂Φ (x)
∂J
(x)
klm
+
∂Φ (y)
∂J
(x)
klm
+
∂Φ (z)
∂J
(x)
klm
∂Φ
∂J
(y)
klm
=
∂Φ (R)
∂J
(y)
klm
+
∂Φ (x)
∂J
(y)
klm
+
∂Φ (y)
∂J
(y)
klm
+
∂Φ (z)
∂J
(y)
klm
∂Φ
∂J
(z)
klm
=
∂Φ (R)
∂J
(z)
klm
+
∂Φ (x)
∂J
(z)
klm
+
∂Φ (y)
∂J
(z)
klm
+
∂Φ (z)
∂J
(z)
klm
∂Φ
∂ρ klm
=
∂Φ (x)
∂ρ klm
+
∂Φ (y)
∂ρ klm
+
∂Φ (z)
∂ρ klm
.
(1.15)
Eventually we will need to minimize Φ along the line (ρ, J (x) , J (y) , J (z) ) +
α(u, v (x) , v (y) , v (z) ) in function-space. α is a real number that parameterizes the line,
(ρ, J (x) , J (y) , J (z) ) is a fixed starting point, and (u, v (x) , v (y) , v (z) ) is a directionvector that will be determined by the conjugate-gradient algorithm. We will do this
by differentiating Φ with respect to α, and then set the derivative equal to zero to
determine the optimum α.
From (1.9), we have
Φ(ρ + αu, J
(x)
+ αv
(x) , J
(y)
+ αv
(y) , J
(z)
+ αv
(z) ) =
Φ
(R) (J
(x)
+ αv
(x) , J
(y)
+ αv
(y) , J
(z)
+ αv
(z) ) +
Φ
(x) (ρ + αu, J
(x)
+ αv
(x) , J
(y)
+ αv
(y) , J
(z)
+ αv
(z) ) +
Φ
(y) (ρ + αu, J
(x)
+ αv
(x) , J
(y)
+ αv
(y) , J
(z)
+ αv
(z) ) +
Φ
(z) (ρ + αu, J
(x)
+ αv
(x) , J
(y)
+ αv
(y) , J
(z)
+ αv
(z) ) .
(1.16)
Clearly, Φ (R) (J + αv) is quadratic in α, but the other three functionals are of the
fourth-order in α, as can be seen by the bilinear function E(ρ, J) that is defined in
(1.3) and appears in (1.9).