

4.8 Handling Rotations of Anisotropic Media
121
where
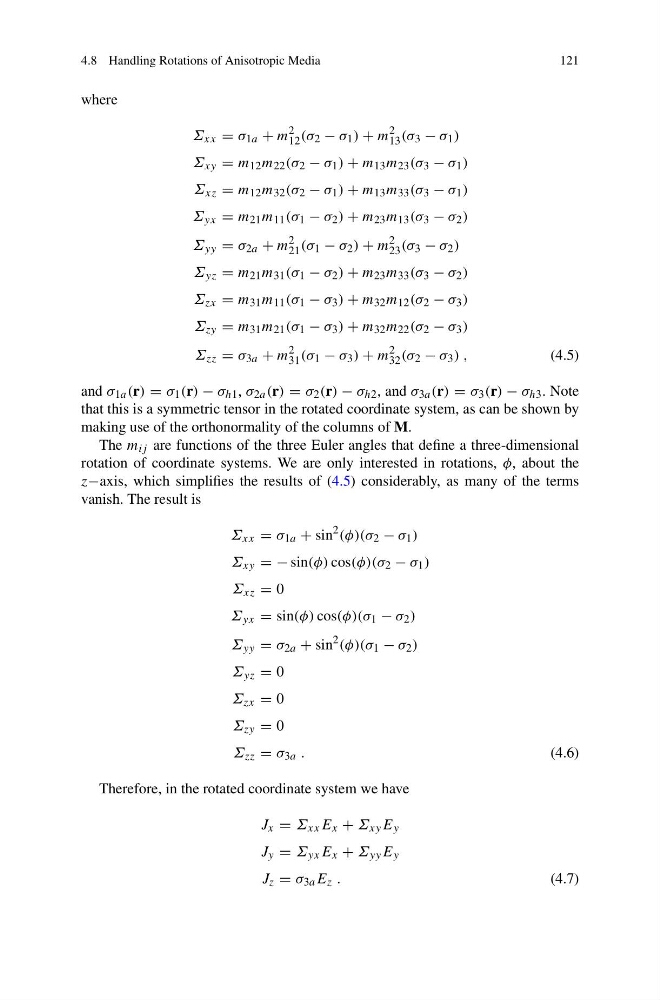
Σ xx = σ 1a + m
2
12 (σ 2 − σ 1 ) + m
2
13 (σ 3 − σ 1 )
Σ xy = m 12 m 22 (σ 2 − σ 1 ) + m 13 m 23 (σ 3 − σ 1 )
Σ xz = m 12 m 32 (σ 2 − σ 1 ) + m 13 m 33 (σ 3 − σ 1 )
Σ yx = m 21 m 11 (σ 1 − σ 2 ) + m 23 m 13 (σ 3 − σ 2 )
Σ yy = σ 2a + m
2
21 (σ 1 − σ 2 ) + m
2
23 (σ 3 − σ 2 )
Σ yz = m 21 m 31 (σ 1 − σ 2 ) + m 23 m 33 (σ 3 − σ 2 )
Σ zx = m 31 m 11 (σ 1 − σ 3 ) + m 32 m 12 (σ 2 − σ 3 )
Σ zy = m 31 m 21 (σ 1 − σ 3 ) + m 32 m 22 (σ 2 − σ 3 )
Σ zz = σ 3a + m
2
31 (σ 1 − σ 3 ) + m
2
32 (σ 2 − σ 3 ) ,
(4.5)
and σ 1a (r) = σ 1 (r) − σ h1 , σ 2a (r) = σ 2 (r) − σ h2 , and σ 3a (r) = σ 3 (r) − σ h3 . Note
that this is a symmetric tensor in the rotated coordinate system, as can be shown by
making use of the orthonormality of the columns of M.
The m ij are functions of the three Euler angles that define a three-dimensional
rotation of coordinate systems. We are only interested in rotations, φ, about the
z−axis, which simplifies the results of (4.5) considerably, as many of the terms
vanish. The result is
Σ xx = σ 1a + sin
2 (φ)(σ 2 − σ 1 )
Σ xy = − sin(φ) cos(φ)(σ 2 − σ 1 )
Σ xz = 0
Σ yx = sin(φ) cos(φ)(σ 1 − σ 2 )
Σ yy = σ 2a + sin
2 (φ)(σ 1 − σ 2 )
Σ yz = 0
Σ zx = 0
Σ zy = 0
Σ zz = σ 3a .
(4.6)
Therefore, in the rotated coordinate system we have
J x = Σ xx E x + Σ xy E y
J y = Σ yx E x + Σ yy E y
J z = σ 3a E z .
(4.7)