

11.2 Motivating Example
395
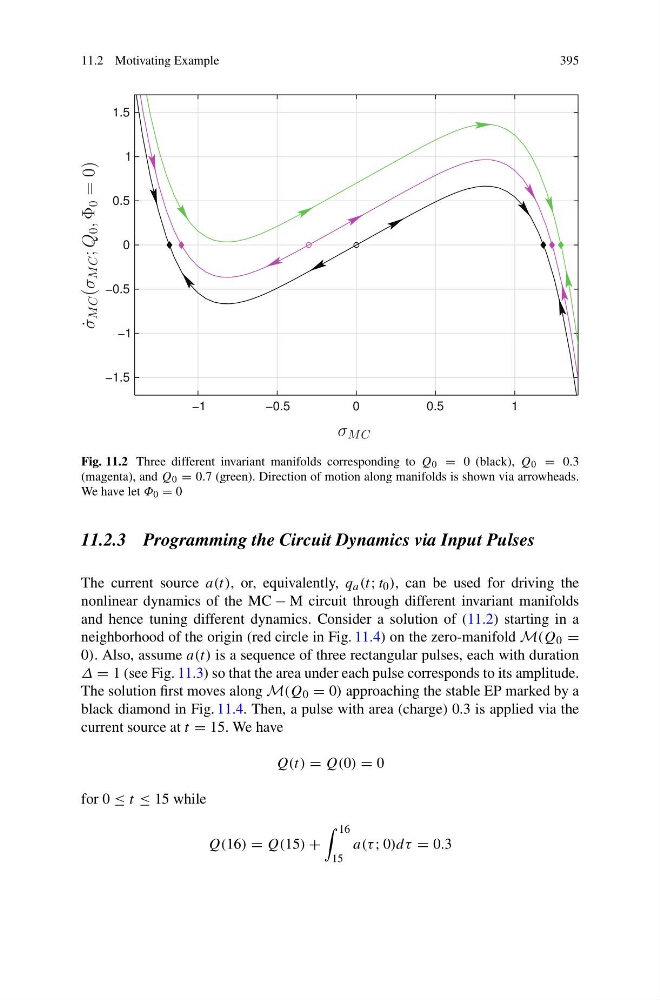
Fig. 11.2 Three different invariant manifolds corresponding to Q 0 = 0 (black), Q 0 = 0.3
(magenta), and Q 0 = 0.7 (green). Direction of motion along manifolds is shown via arrowheads.
We have let Φ 0 = 0
11.2.3 Programming the Circuit Dynamics via Input Pulses
The current source a(t), or, equivalently, q a (t; t 0 ), can be used for driving the
nonlinear dynamics of the MC − M circuit through different invariant manifolds
and hence tuning different dynamics. Consider a solution of (11.2) starting in a
neighborhood of the origin (red circle in Fig. 11.4) on the zero-manifold M(Q 0 =
0). Also, assume a(t) is a sequence of three rectangular pulses, each with duration
Δ = 1 (see Fig. 11.3) so that the area under each pulse corresponds to its amplitude.
The solution first moves along M(Q 0 = 0) approaching the stable EP marked by a
black diamond in Fig. 11.4. Then, a pulse with area (charge) 0.3 is applied via the
current source at t = 15. We have
Q(t) = Q(0) = 0
for 0 ≤ t ≤ 15 while
Q(16) = Q(15) +
16
15
a(τ ; 0)dτ = 0.3