

6.3 Third-Order Memristor Chaotic Circuits
257
1
R
˙
X =
1
R + r
( ˙
ϕ M + L
di L
dt
+ rC 2 ˙
v C 2 ) +
df (ϕ M )
dt
+ C 1 ˙
v C 1
(6.44)
=
1
R + r
(v C 1 − ri L − v C 2 −
r
R
v C 2 +
r
R
v C 1 −
r
R
i L )
(6.45)
+
1
R
(v C 2 − v C 1 ) − G(ϕ M )v C 1 + G(ϕ M )v C 1 = 0
(6.46)
for any t ≥ t 0 .
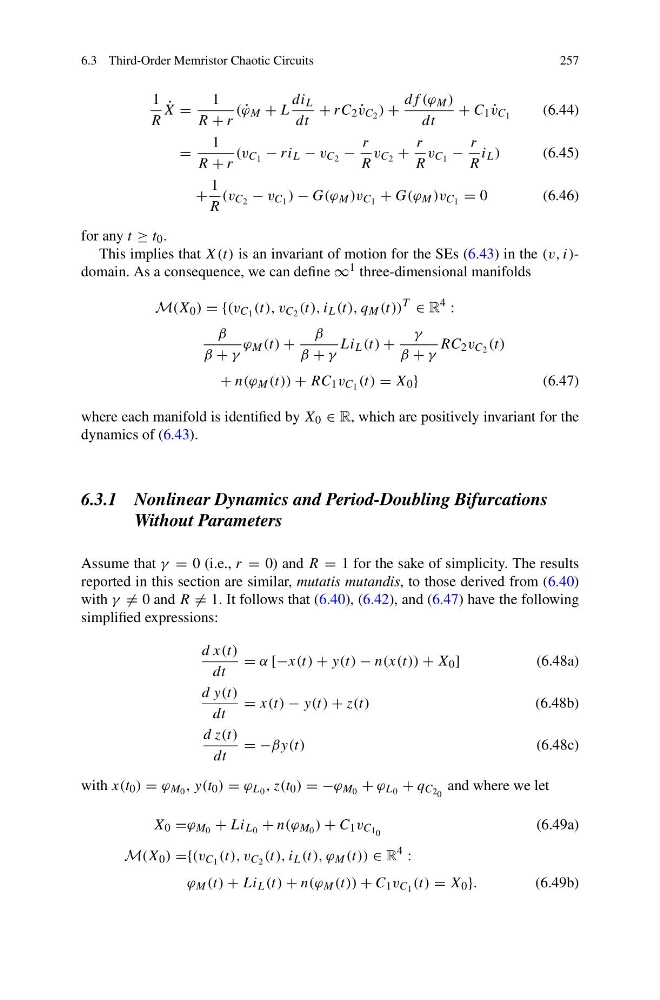
This implies that X(t) is an invariant of motion for the SEs (6.43) in the (v, i)domain. As a consequence, we can define ∞ 1 three-dimensional manifolds
M(X 0 ) = {(v C 1 (t), v C 2 (t), i L (t), q M (t))
T
∈ R
4
:
β
β + γ
ϕ M (t) +
β
β + γ
Li L (t) +
γ
β + γ
RC 2 v C 2 (t)
+ n(ϕ M (t)) + RC 1 v C 1 (t) = X 0 }
(6.47)
where each manifold is identified by X 0 ∈ R, which are positively invariant for the
dynamics of (6.43).
6.3.1 Nonlinear Dynamics and Period-Doubling Bifurcations
Without Parameters
Assume that γ = 0 (i.e., r = 0) and R = 1 for the sake of simplicity. The results
reported in this section are similar, mutatis mutandis, to those derived from (6.40)
with γ = 0 and R = 1. It follows that (6.40), (6.42), and (6.47) have the following
simplified expressions:
d x(t)
dt
= α [−x(t) + y(t) − n(x(t)) + X 0 ]
(6.48a)
d y(t)
dt
= x(t) − y(t) + z(t)
(6.48b)
d z(t)
dt
= −βy(t)
(6.48c)
with x(t 0 ) = ϕ M 0 , y(t 0 ) = ϕ L 0 , z(t 0 ) = −ϕ M 0 + ϕ L 0 + q C 2 0 and where we let
X 0 =ϕ M 0 + Li L 0 + n(ϕ M 0 ) + C 1 v C 1 0
(6.49a)
M(X 0 ) ={(v C 1 (t), v C 2 (t), i L (t), ϕ M (t)) ∈ R
4
:
ϕ M (t) + Li L (t) + n(ϕ M (t)) + C 1 v C 1 (t) = X 0 }.
(6.49b)