

132
4 Nonlinear Dynamics and Bifurcations in Autonomous RLC Circuits
C = 1 F
+
−
v
i
vC
iC
+
−
ˆ i(v)
−3
−2
−1
1
2
3
−2
−1
1
2
v
i = ˆ i(v)
)
b
(
)
a
(
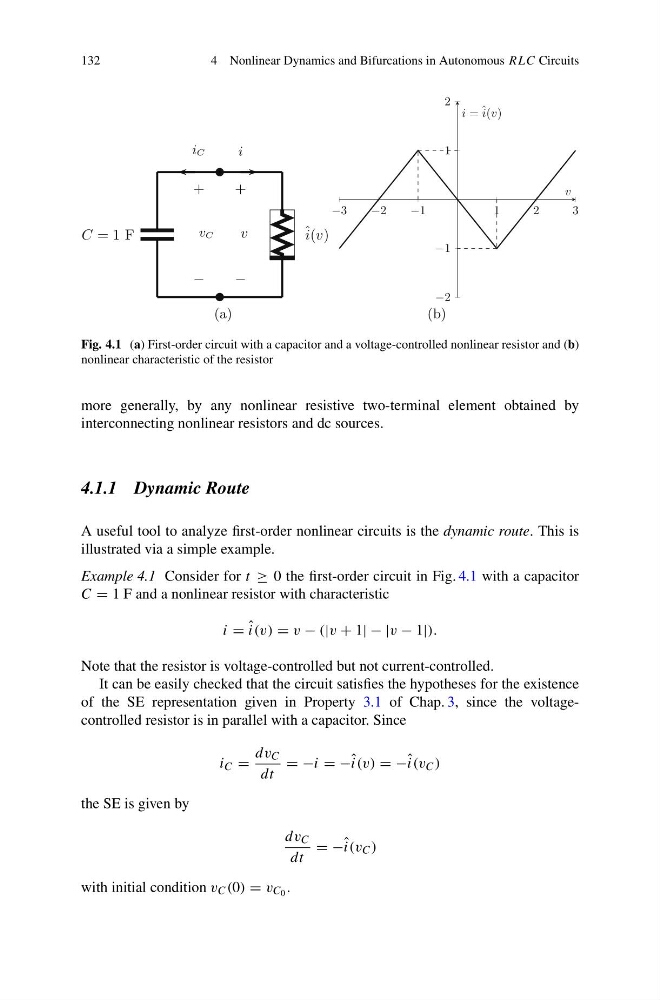
Fig. 4.1 (a) First-order circuit with a capacitor and a voltage-controlled nonlinear resistor and (b)
nonlinear characteristic of the resistor
more generally, by any nonlinear resistive two-terminal element obtained by
interconnecting nonlinear resistors and dc sources.
4.1.1 Dynamic Route
A useful tool to analyze first-order nonlinear circuits is the dynamic route. This is
illustrated via a simple example.
Example 4.1 Consider for t ≥ 0 the first-order circuit in Fig. 4.1 with a capacitor
C = 1 F and a nonlinear resistor with characteristic
i = ˆ
i(v) = v − (|v + 1| − |v − 1|).
Note that the resistor is voltage-controlled but not current-controlled.
It can be easily checked that the circuit satisfies the hypotheses for the existence
of the SE representation given in Property 3.1 of Chap. 3, since the voltagecontrolled resistor is in parallel with a capacitor. Since
i C =
dv C
dt
= −i = − ˆ
i(v) = − ˆ
i(v C )
the SE is given by
dv C
dt
= − ˆ
i(v C )
with initial condition v C (0) = v C 0 .