

13.4 Application of Special Measurement Technology
445
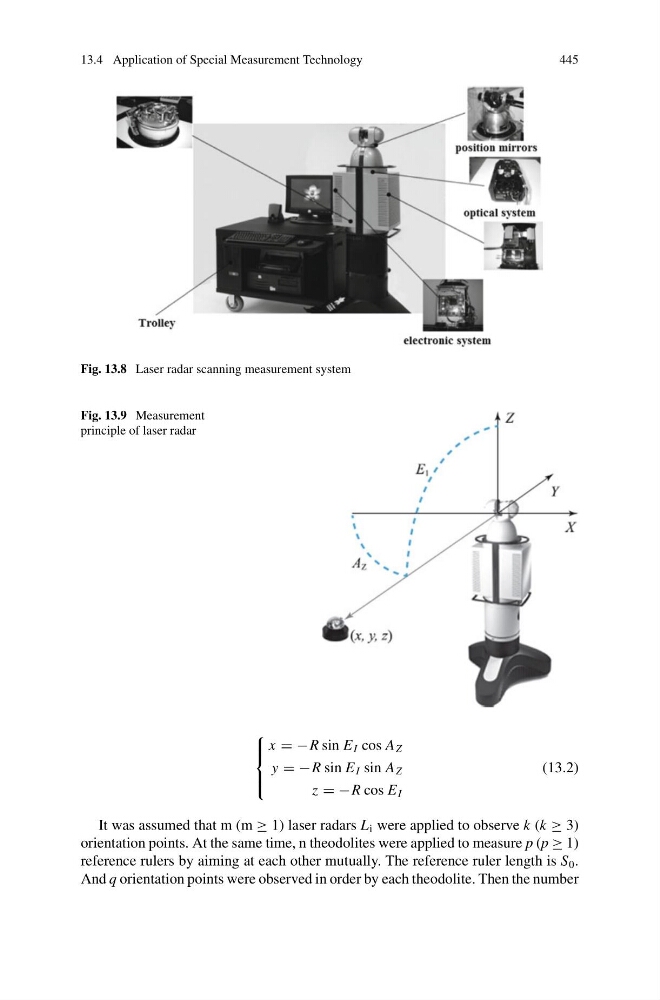
Fig. 13.8 Laser radar scanning measurement system
Fig. 13.9 Measurement
principle of laser radar
⎧
⎪ ⎨
⎪ ⎩
x = −R sin E I cos A Z
y = −R sin E I sin A Z
z = −R cos E I
(13.2)
It was assumed that m (m ≥ 1) laser radars L i were applied to observe k (k ≥ 3)
orientation points. At the same time, n theodolites were applied to measure p (p ≥ 1)
reference rulers by aiming at each other mutually. The reference ruler length is S 0 .
And q orientation points were observed in order by each theodolite. Then the number