

7.7 Summary
265
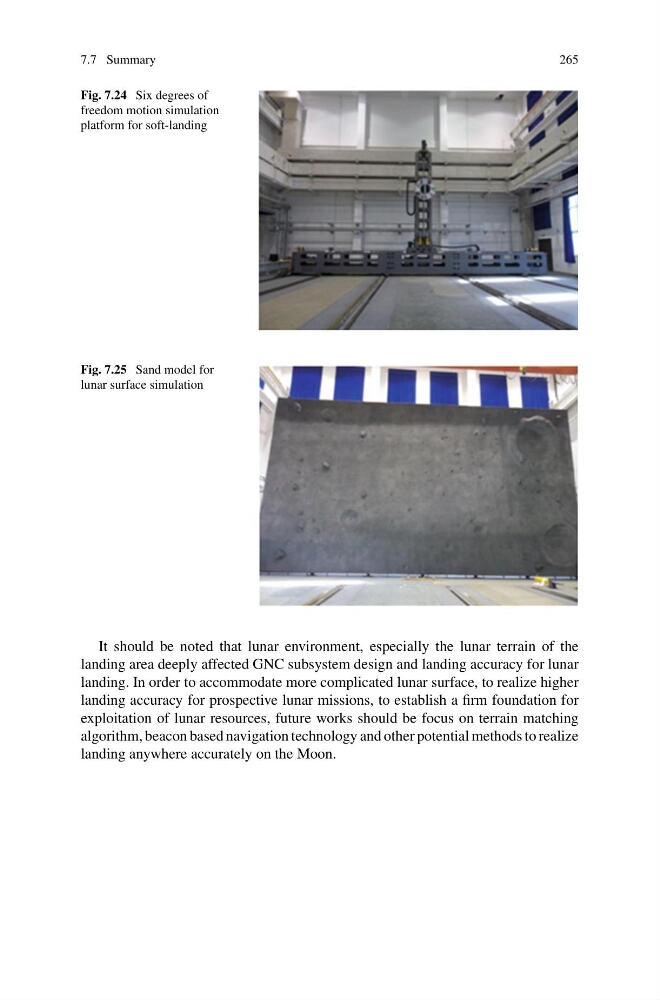
Fig. 7.24 Six degrees of
freedom motion simulation
platform for soft-landing
Fig. 7.25 Sand model for
lunar surface simulation
It should be noted that lunar environment, especially the lunar terrain of the
landing area deeply affected GNC subsystem design and landing accuracy for lunar
landing. In order to accommodate more complicated lunar surface, to realize higher
landing accuracy for prospective lunar missions, to establish a firm foundation for
exploitation of lunar resources, future works should be focus on terrain matching
algorithm, beacon based navigation technology and other potential methods to realize
landing anywhere accurately on the Moon.