

262
7 Guidance, Navigation and Control Technology …
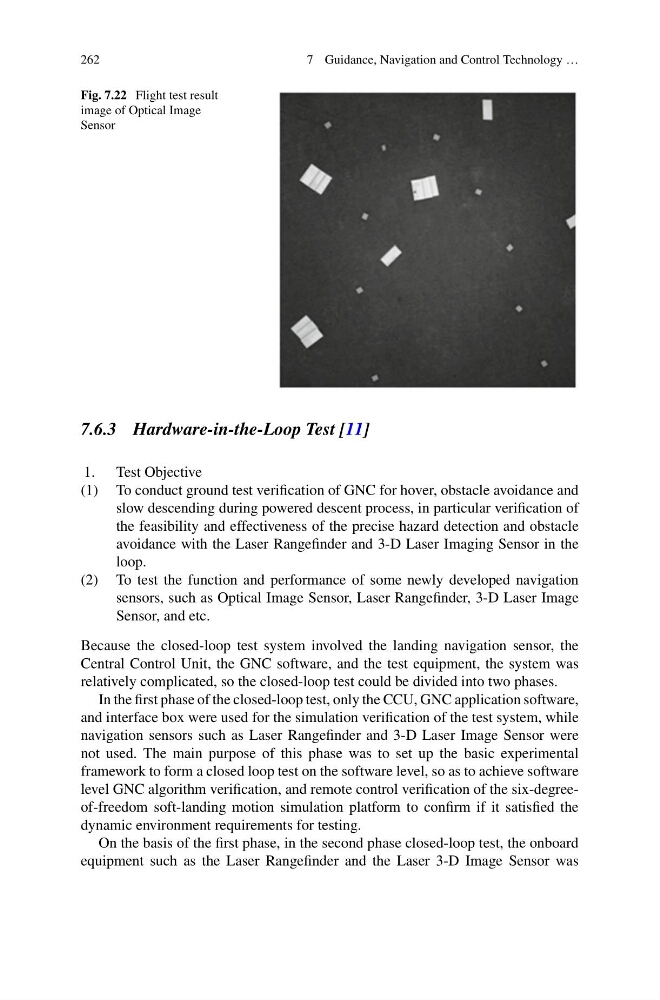
Fig. 7.22 Flight test result
image of Optical Image
Sensor
7.6.3 Hardware-in-the-Loop Test [11]
1. Test Objective
(1) To conduct ground test verification of GNC for hover, obstacle avoidance and
slow descending during powered descent process, in particular verification of
the feasibility and effectiveness of the precise hazard detection and obstacle
avoidance with the Laser Rangefinder and 3-D Laser Imaging Sensor in the
loop.
(2) To test the function and performance of some newly developed navigation
sensors, such as Optical Image Sensor, Laser Rangefinder, 3-D Laser Image
Sensor, and etc.
Because the closed-loop test system involved the landing navigation sensor, the
Central Control Unit, the GNC software, and the test equipment, the system was
relatively complicated, so the closed-loop test could be divided into two phases.
In the first phase of the closed-loop test, only the CCU, GNC application software,
and interface box were used for the simulation verification of the test system, while
navigation sensors such as Laser Rangefinder and 3-D Laser Image Sensor were
not used. The main purpose of this phase was to set up the basic experimental
framework to form a closed loop test on the software level, so as to achieve software
level GNC algorithm verification, and remote control verification of the six-degreeof-freedom soft-landing motion simulation platform to confirm if it satisfied the
dynamic environment requirements for testing.
On the basis of the first phase, in the second phase closed-loop test, the onboard
equipment such as the Laser Rangefinder and the Laser 3-D Image Sensor was