

7.6 Testing and Verification
261
7.6.2 GNC Subsystem Flight Testing
1) Test objective
The purpose of the subsystem flight test was to use the components outdoor field test
as a basis to specify the special operating dynamics environment of the subsystem and
to verify the performance of the navigation sensor under specific dynamics between
2 km ~ 100 m during lunar landing.
2) Test method
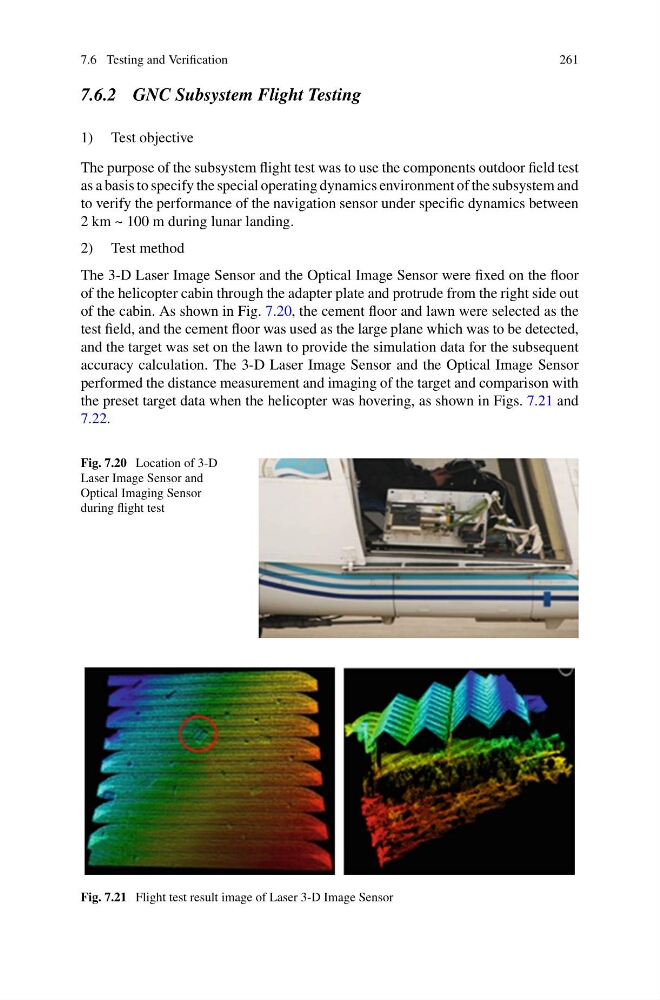
The 3-D Laser Image Sensor and the Optical Image Sensor were fixed on the floor
of the helicopter cabin through the adapter plate and protrude from the right side out
of the cabin. As shown in Fig. 7.20, the cement floor and lawn were selected as the
test field, and the cement floor was used as the large plane which was to be detected,
and the target was set on the lawn to provide the simulation data for the subsequent
accuracy calculation. The 3-D Laser Image Sensor and the Optical Image Sensor
performed the distance measurement and imaging of the target and comparison with
the preset target data when the helicopter was hovering, as shown in Figs. 7.21 and
7.22.
Fig. 7.20 Location of 3-D
Laser Image Sensor and
Optical Imaging Sensor
during flight test
Fig. 7.21 Flight test result image of Laser 3-D Image Sensor