

248
7 Guidance, Navigation and Control Technology …
(5) Hazard avoidance: altitude to actual lunar surface was from about 100 m to
30 m. The main task of this phase was fine hazard avoidance and descending.
According to the selected safe landing point, the lunar lander descended to
30 m above the landing point, the relative descent velocity was predefined (not
more than 2 m/s), the horizontal velocity was close to zero, and the trajectory
was slant to the landing site.
(6) Slow descending: altitude to actual moon surface was about 30 m to the shutdown signal to take effect. The main task of this phase was to ensure that the
lunar lander descended steadily and slowly to lunar surface, and the control
accuracy of velocity and attitude met the requirements. The lander slowed down
at a preset relative velocity to lunar surface, eliminated the horizontal velocity
with an attitude vertically to the lunar surface. Until receiving the shutdown
sensor signal, the control computer provided command to shut off the main
engine and the thrusters, free falling to lunar surface, and the trajectory was
almost vertical.
7.5.3 Navigation Method for Powered Descent Phase
The conventional autonomous navigation for powered descent process is inertial
navigation with correction by information of range and velocity sensors. In order to
further improve the navigation accuracy, image matching navigation could be used.
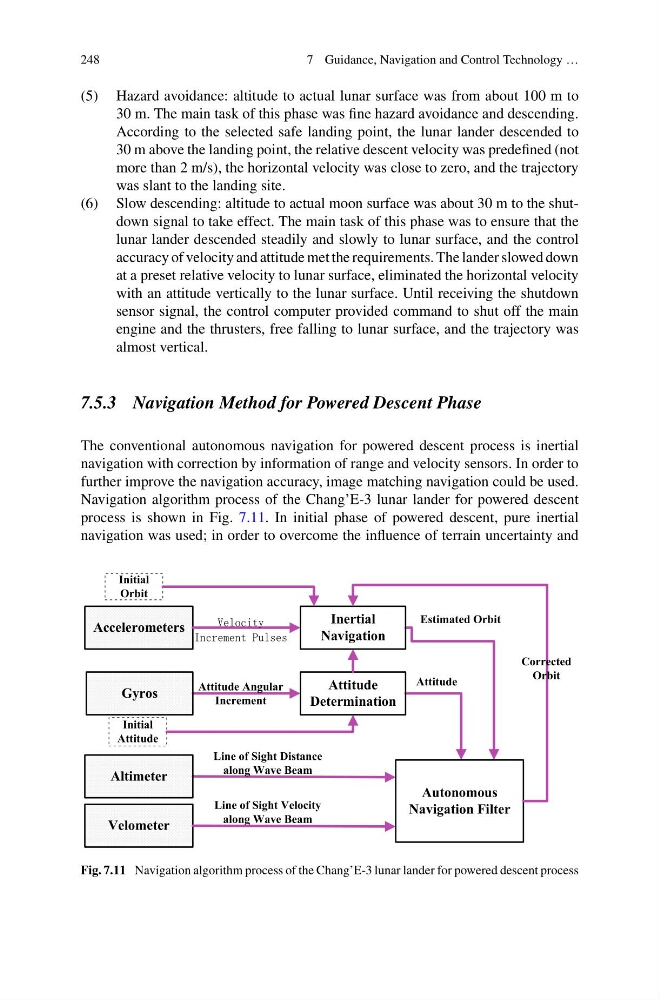
Navigation algorithm process of the Chang’E-3 lunar lander for powered descent
process is shown in Fig. 7.11. In initial phase of powered descent, pure inertial
navigation was used; in order to overcome the influence of terrain uncertainty and
Accelerometers
Initial
Orbit
Attitude
Determination
Gyros
Altimeter
Velometer
Inertial
Navigation
Autonomous
Navigation Filter
Line of Sight Distance
along Wave Beam
Line of Sight Velocity
along Wave Beam
Velocity
Increment Pulses
Attitude Angular
Increment
Estimated Orbit
Attitude
Corrected
Orbit
Initial
Attitude
Fig. 7.11 Navigation algorithm process of the Chang’E-3 lunar lander for powered descent process