

242
7 Guidance, Navigation and Control Technology …
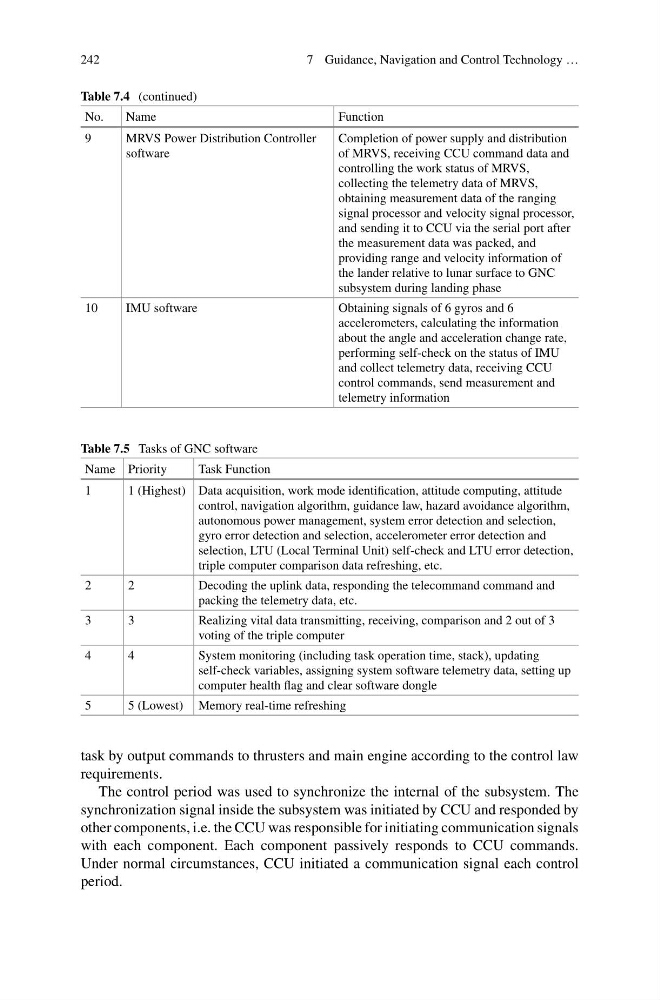
Table 7.4 (continued)
No.
Name
Function
9
MRVS Power Distribution Controller
software
Completion of power supply and distribution
of MRVS, receiving CCU command data and
controlling the work status of MRVS,
collecting the telemetry data of MRVS,
obtaining measurement data of the ranging
signal processor and velocity signal processor,
and sending it to CCU via the serial port after
the measurement data was packed, and
providing range and velocity information of
the lander relative to lunar surface to GNC
subsystem during landing phase
10
IMU software
Obtaining signals of 6 gyros and 6
accelerometers, calculating the information
about the angle and acceleration change rate,
performing self-check on the status of IMU
and collect telemetry data, receiving CCU
control commands, send measurement and
telemetry information
Table 7.5 Tasks of GNC software
Name Priority
Task Function
1
1 (Highest) Data acquisition, work mode identification, attitude computing, attitude
control, navigation algorithm, guidance law, hazard avoidance algorithm,
autonomous power management, system error detection and selection,
gyro error detection and selection, accelerometer error detection and
selection, LTU (Local Terminal Unit) self-check and LTU error detection,
triple computer comparison data refreshing, etc.
2
2
Decoding the uplink data, responding the telecommand command and
packing the telemetry data, etc.
3
3
Realizing vital data transmitting, receiving, comparison and 2 out of 3
voting of the triple computer
4
4
System monitoring (including task operation time, stack), updating
self-check variables, assigning system software telemetry data, setting up
computer health flag and clear software dongle
5
5 (Lowest) Memory real-time refreshing
task by output commands to thrusters and main engine according to the control law
requirements.
The control period was used to synchronize the internal of the subsystem. The
synchronization signal inside the subsystem was initiated by CCU and responded by
other components, i.e. the CCU was responsible for initiating communication signals
with each component. Each component passively responds to CCU commands.
Under normal circumstances, CCU initiated a communication signal each control
period.