

7.4 Design Methodology
241
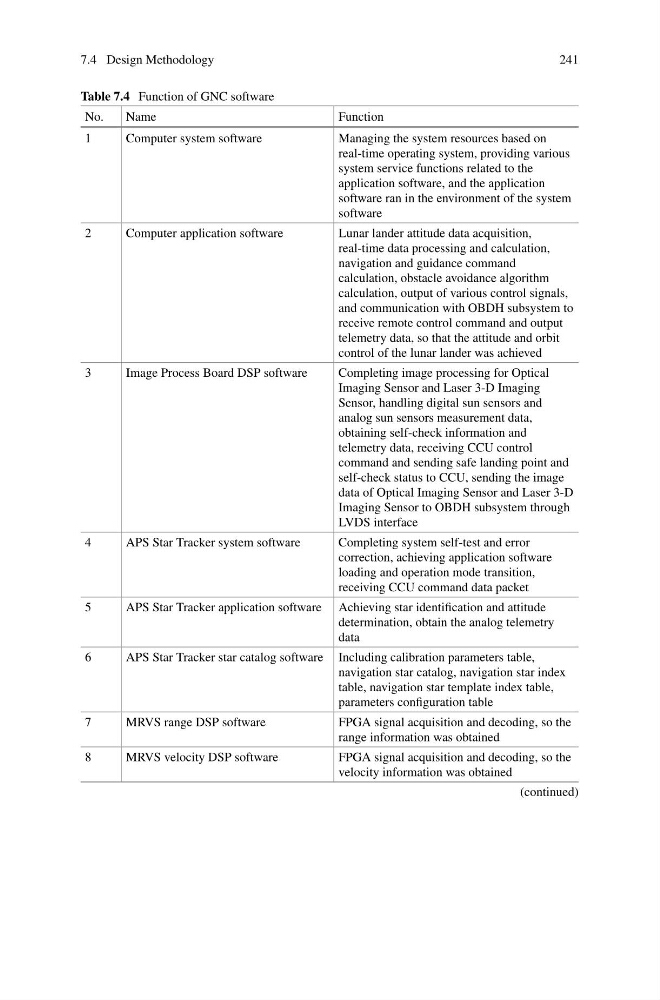
Table 7.4 Function of GNC software
No.
Name
Function
1
Computer system software
Managing the system resources based on
real-time operating system, providing various
system service functions related to the
application software, and the application
software ran in the environment of the system
software
2
Computer application software
Lunar lander attitude data acquisition,
real-time data processing and calculation,
navigation and guidance command
calculation, obstacle avoidance algorithm
calculation, output of various control signals,
and communication with OBDH subsystem to
receive remote control command and output
telemetry data, so that the attitude and orbit
control of the lunar lander was achieved
3
Image Process Board DSP software
Completing image processing for Optical
Imaging Sensor and Laser 3-D Imaging
Sensor, handling digital sun sensors and
analog sun sensors measurement data,
obtaining self-check information and
telemetry data, receiving CCU control
command and sending safe landing point and
self-check status to CCU, sending the image
data of Optical Imaging Sensor and Laser 3-D
Imaging Sensor to OBDH subsystem through
LVDS interface
4
APS Star Tracker system software
Completing system self-test and error
correction, achieving application software
loading and operation mode transition,
receiving CCU command data packet
5
APS Star Tracker application software Achieving star identification and attitude
determination, obtain the analog telemetry
data
6
APS Star Tracker star catalog software Including calibration parameters table,
navigation star catalog, navigation star index
table, navigation star template index table,
parameters configuration table
7
MRVS range DSP software
FPGA signal acquisition and decoding, so the
range information was obtained
8
MRVS velocity DSP software
FPGA signal acquisition and decoding, so the
velocity information was obtained
(continued)