

22
H. Nakao
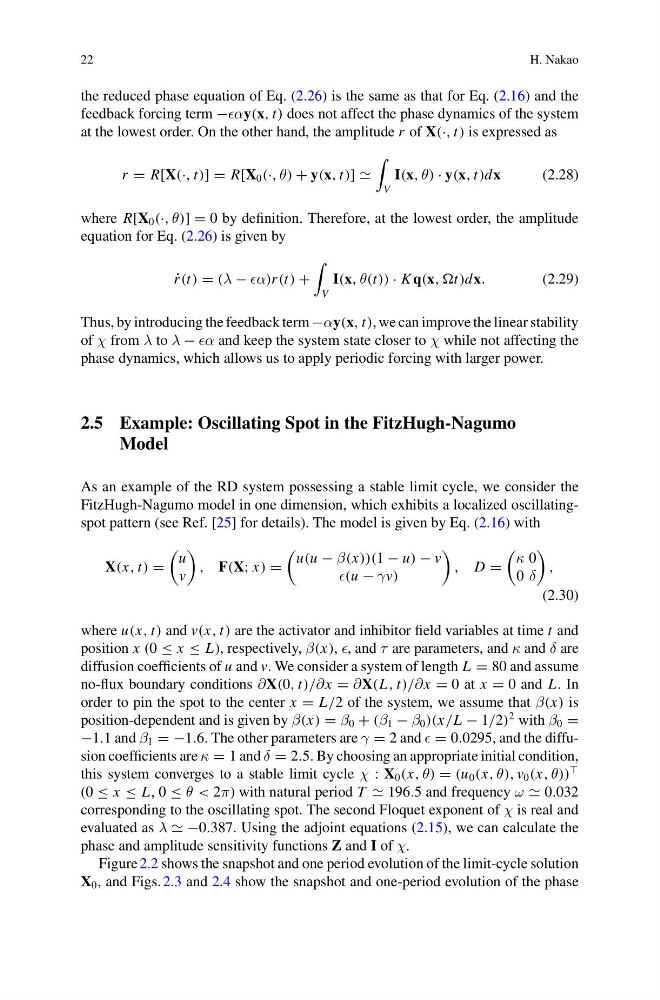
the reduced phase equation of Eq. (2.26) is the same as that for Eq. (2.16) and the
feedback forcing term −αy(x, t) does not affect the phase dynamics of the system
at the lowest order. On the other hand, the amplitude r of X(·, t) is expressed as
r = R[X(·, t)] = R[X 0 (·, θ) + y(x, t)] ]
V
I(x, θ) · y(x, t)dx
(2.28)
where R[X 0 (·, θ)] = 0 by definition. Therefore, at the lowest order, the amplitude
equation for Eq. (2.26) is given by
˙
r (t) = (λ − α)r (t) +
V
I(x, θ(t)) · K q(x, ,t)dx.
(2.29)
Thus, by introducing the feedback term −αy(x, t), we can improve the linear stability
of χ from λ to λ − α and keep the system state closer to χ while not affecting the
phase dynamics, which allows us to apply periodic forcing with larger power.
2.5 Example: Oscillating Spot in the FitzHugh-Nagumo
Model
As an example of the RD system possessing a stable limit cycle, we consider the
FitzHugh-Nagumo model in one dimension, which exhibits a localized oscillatingspot pattern (see Ref. [25] for details). The model is given by Eq. (2.16) with
X(x, t) =
u
v
, F(X; x) =
u(u − β(x))(1 − u) − v
(u − γv)
, D =
κ 0
0 δ
,
(2.30)
where u(x, t) and v(x, t) are the activator and inhibitor field variables at time t and
position x (0 ≤ x ≤ L), respectively, β(x), , and τ are parameters, and κ and δ are
diffusion coefficients of u and v. We consider a system of length L = 80 and assume
no-flux boundary conditions ∂X(0, t)/∂x = ∂X(L , t)/∂x = 0 at x = 0 and L. In
order to pin the spot to the center x = L/2 of the system, we assume that β(x) is
position-dependent and is given by β(x) = β 0 + (β 1 − β 0 )(x/L − 1/2)
2 with β 0 =
−1.1 and β 1 = −1.6. The other parameters are γ = 2 and = 0.0295, and the diffusion coefficients are κ = 1 and δ = 2.5. By choosing an appropriate initial condition,
this system converges to a stable limit cycle χ : X 0 (x, θ) = (u 0 (x, θ), v 0 (x, θ))
(0 ≤ x ≤ L, 0 ≤ θ < 2π) with natural period T 196.5 and frequency ω 0.032
corresponding to the oscillating spot. The second Floquet exponent of χ is real and
evaluated as λ −0.387. Using the adjoint equations (2.15), we can calculate the
phase and amplitude sensitivity functions Z and I of χ.
Figure 2.2 shows the snapshot and one period evolution of the limit-cycle solution
X 0 , and Figs. 2.3 and 2.4 show the snapshot and one-period evolution of the phase