

374
J. Gao et al.
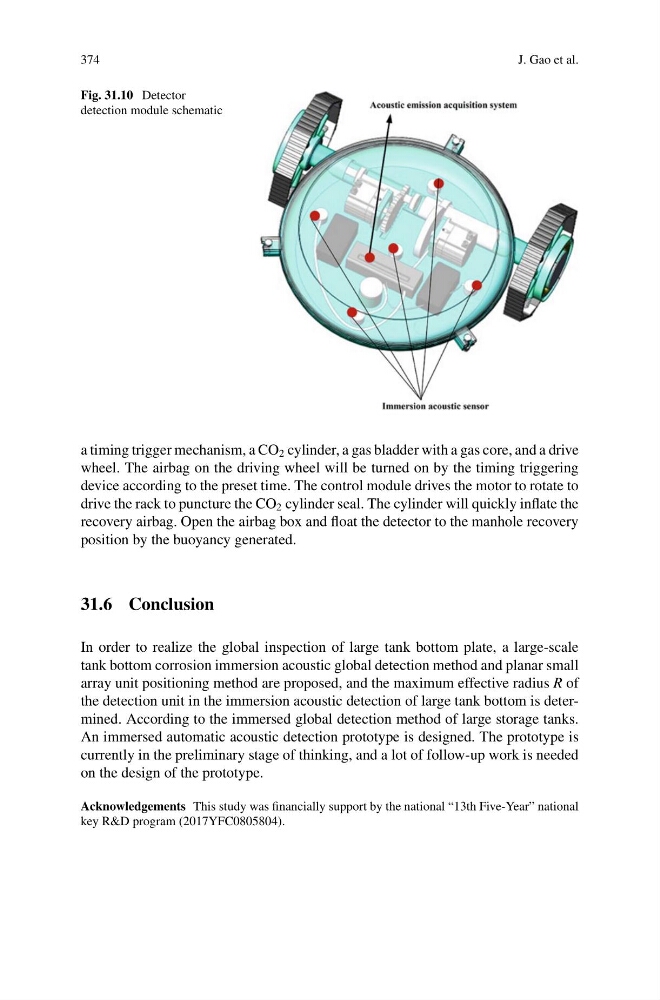
Fig. 31.10 Detector
detection module schematic
a timing trigger mechanism, a CO 2 cylinder, a gas bladder with a gas core, and a drive
wheel. The airbag on the driving wheel will be turned on by the timing triggering
device according to the preset time. The control module drives the motor to rotate to
drive the rack to puncture the CO 2 cylinder seal. The cylinder will quickly inflate the
recovery airbag. Open the airbag box and float the detector to the manhole recovery
position by the buoyancy generated.
31.6 Conclusion
In order to realize the global inspection of large tank bottom plate, a large-scale
tank bottom corrosion immersion acoustic global detection method and planar small
array unit positioning method are proposed, and the maximum effective radius R of
the detection unit in the immersion acoustic detection of large tank bottom is determined. According to the immersed global detection method of large storage tanks.
An immersed automatic acoustic detection prototype is designed. The prototype is
currently in the preliminary stage of thinking, and a lot of follow-up work is needed
on the design of the prototype.
Acknowledgements This study was financially support by the national “13th Five-Year” national
key R&D program (2017YFC0805804).