

372
J. Gao et al.
In the above formula, x is the sound source distance; y is the relative error of the
sound source ranging. The R-square (that is, the coefficient of determination) of the
equation is 0.98, indicating that the fitting effect is better.
When the relative error of the ranging is 20%, the distance of the sound source
from the center of the sensor array is calculated by (31.5) to be 6.27 m. Therefore,
through the verification experiment, when the above method is used for the immersion
acoustic detection of the tank bottom plate, the maximum effective radius R of the
detecting unit can be 6 m.
31.5 Immersion Automatic Acoustic Detector Prototype
Design
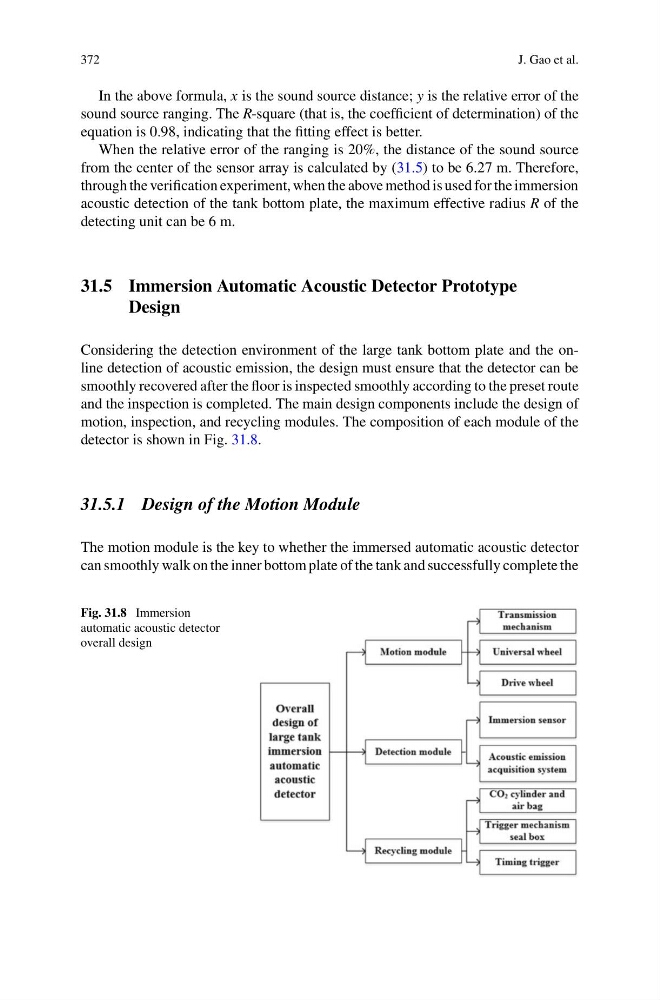
Considering the detection environment of the large tank bottom plate and the online detection of acoustic emission, the design must ensure that the detector can be
smoothly recovered after the floor is inspected smoothly according to the preset route
and the inspection is completed. The main design components include the design of
motion, inspection, and recycling modules. The composition of each module of the
detector is shown in Fig. 31.8.
31.5.1 Design of the Motion Module
The motion module is the key to whether the immersed automatic acoustic detector
can smoothly walk on the inner bottom plate of the tank and successfully complete the
Fig. 31.8 Immersion
automatic acoustic detector
overall design