

6
L. Dong
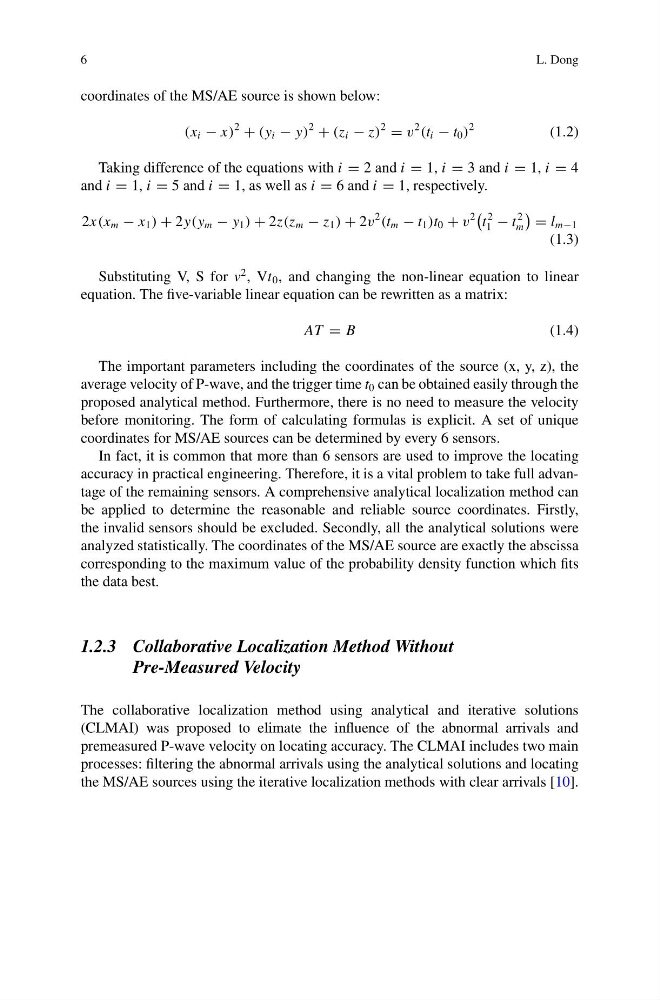
coordinates of the MS/AE source is shown below:
(x i − x)
2
+ (y i − y)
2
+ (z i − z)
2
= v
2
(t i − t 0 )
2
(1.2)
Taking difference of the equations with i = 2 and i = 1, i = 3 and i = 1, i = 4
and i = 1, i = 5 and i = 1, as well as i = 6 and i = 1, respectively.
2x(x m − x 1 ) + 2y(y m − y 1 ) + 2z(z m − z 1 ) + 2v
2
(t m − t 1 )t 0 + v
2
t
2
1 − t
2
m
= l m−1
(1.3)
Substituting V, S for v
2 , Vt 0 , and changing the non-linear equation to linear
equation. The five-variable linear equation can be rewritten as a matrix:
AT = B
(1.4)
The important parameters including the coordinates of the source (x, y, z), the
average velocity of P-wave, and the trigger time t 0 can be obtained easily through the
proposed analytical method. Furthermore, there is no need to measure the velocity
before monitoring. The form of calculating formulas is explicit. A set of unique
coordinates for MS/AE sources can be determined by every 6 sensors.
In fact, it is common that more than 6 sensors are used to improve the locating
accuracy in practical engineering. Therefore, it is a vital problem to take full advantage of the remaining sensors. A comprehensive analytical localization method can
be applied to determine the reasonable and reliable source coordinates. Firstly,
the invalid sensors should be excluded. Secondly, all the analytical solutions were
analyzed statistically. The coordinates of the MS/AE source are exactly the abscissa
corresponding to the maximum value of the probability density function which fits
the data best.
1.2.3 Collaborative Localization Method Without
Pre-Measured Velocity
The collaborative localization method using analytical and iterative solutions
(CLMAI) was proposed to elimate the influence of the abnormal arrivals and
premeasured P-wave velocity on locating accuracy. The CLMAI includes two main
processes: filtering the abnormal arrivals using the analytical solutions and locating
the MS/AE sources using the iterative localization methods with clear arrivals [10].