

1 Localization and Discrimination of Microseismic/AE Sources …
5
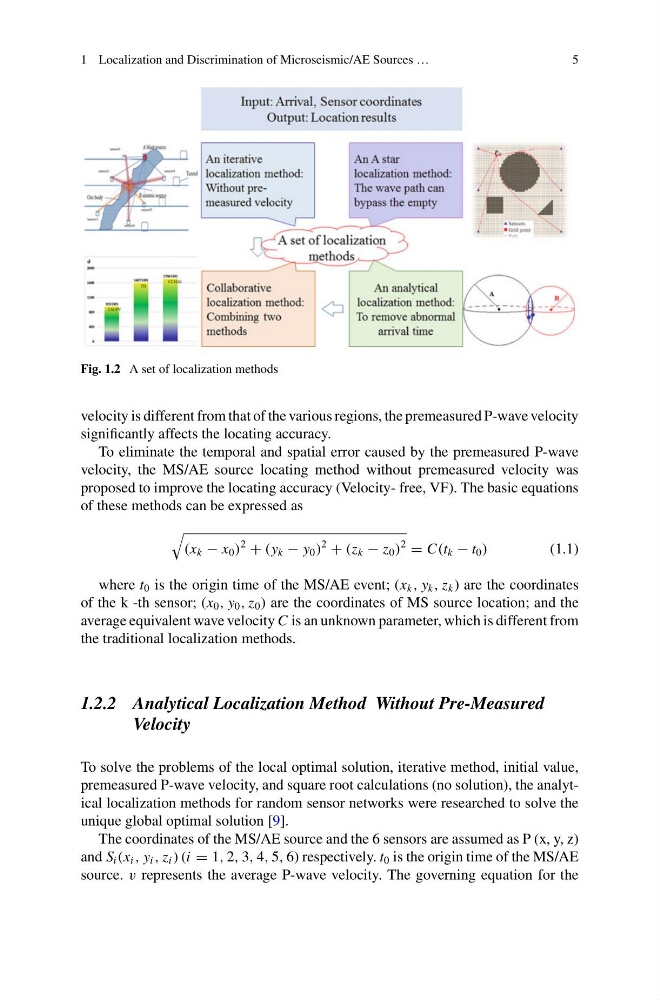
Fig. 1.2 A set of localization methods
velocity is different from that of the various regions, the premeasured P-wave velocity
significantly affects the locating accuracy.
To eliminate the temporal and spatial error caused by the premeasured P-wave
velocity, the MS/AE source locating method without premeasured velocity was
proposed to improve the locating accuracy (Velocity- free, VF). The basic equations
of these methods can be expressed as
(x k − x 0 )
2
+ (y k − y 0 )
2
+ (z k − z 0 )
2
= C(t k − t 0 )
(1.1)
where t 0 is the origin time of the MS/AE event; (x k , y k , z k ) are the coordinates
of the k -th sensor; (x 0 , y 0 , z 0 ) are the coordinates of MS source location; and the
average equivalent wave velocity C is an unknown parameter, which is different from
the traditional localization methods.
1.2.2 Analytical Localization Method Without Pre-Measured
Velocity
To solve the problems of the local optimal solution, iterative method, initial value,
premeasured P-wave velocity, and square root calculations (no solution), the analytical localization methods for random sensor networks were researched to solve the
unique global optimal solution [9].
The coordinates of the MS/AE source and the 6 sensors are assumed as P (x, y, z)
and S i (x i , y i , z i ) (i = 1, 2, 3, 4, 5, 6) respectively. t 0 is the origin time of the MS/AE
source. v represents the average P-wave velocity. The governing equation for the