

142
6 Detection of Radio Signals and Its Parameters Measuring
From (6.30) expression, it follows that at the known priori density, the determining
of posterior density of probability distribution is equivalent to find sufficient statistics,
which is a function of unknown coordinates and parameters of targets movement.
y out (α s ) =
T
0
y(t)S(t, α s )dt
(6.31)
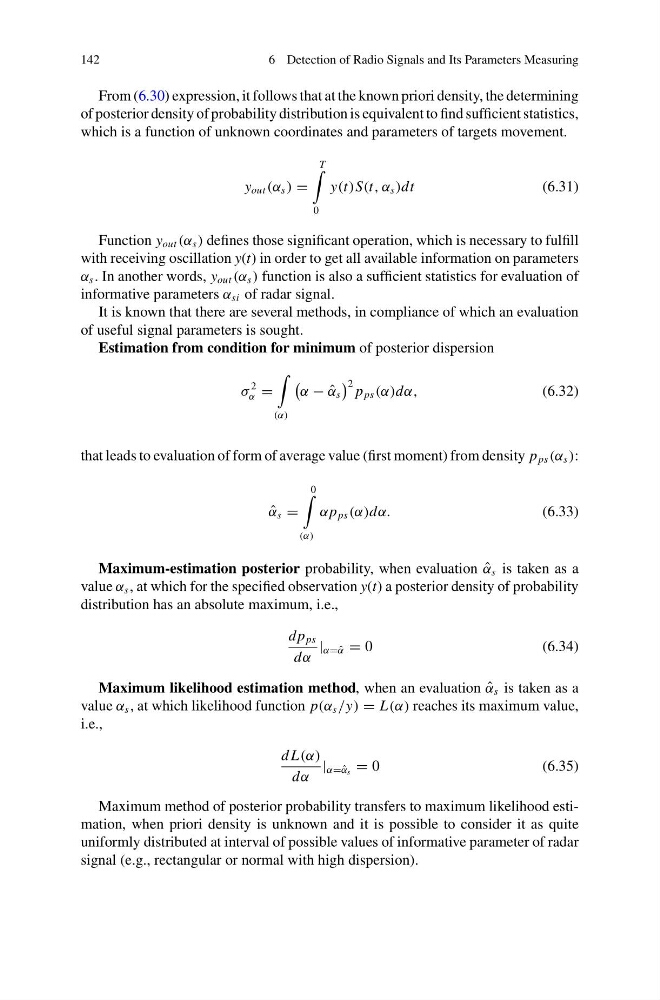
Function y out (α s ) defines those significant operation, which is necessary to fulfill
with receiving oscillation y(t) in order to get all available information on parameters
α s . In another words, y out (α s ) function is also a sufficient statistics for evaluation of
informative parameters α si of radar signal.
It is known that there are several methods, in compliance of which an evaluation
of useful signal parameters is sought.
Estimation from condition for minimum of posterior dispersion
σ
2
α =
(α)
α − ˆ
α s
2 p ps (α)dα,
(6.32)
that leads to evaluation of form of average value (first moment) from density p ps (α s ):
ˆ
α s =
0
(α)
αp ps (α)dα.
(6.33)
Maximum-estimation posterior probability, when evaluation ˆ
α s is taken as a
value α s , at which for the specified observation y(t) a posterior density of probability
distribution has an absolute maximum, i.e.,
dp ps
dα
| α= ˆ
α = 0
(6.34)
Maximum likelihood estimation method, when an evaluation ˆ
α s is taken as a
value α s , at which likelihood function p(α s /y) = L(α) reaches its maximum value,
i.e.,
d L(α)
dα
| α= ˆ
α s = 0
(6.35)
Maximum method of posterior probability transfers to maximum likelihood estimation, when priori density is unknown and it is possible to consider it as quite
uniformly distributed at interval of possible values of informative parameter of radar
signal (e.g., rectangular or normal with high dispersion).