

106
5 Performance Characteristics of Radar Location …
σ l 1 =
cσ τ 1
2 sin
Ψ 1
2
and σ l 2 =
cσ τ 2
2 sin
Ψ 2
2
.
where σ τ 1 and σ τ 2 —mean-square values of navigational parameters finding errors τ 1
and τ 2 , representing a difference of signals arrival moments correspondingly for the
first and for the second pair of stations; 1 and 2 —angles, at which the first and
the second bases of the system are visible.
At independent errors of position lines finding according to (5.47) for mean-square
value of radial calculation error of object position, we obtain:
σ r =
c
σ 2
τ 1
sin
2
1
2
+ σ 2
τ 2
sin
2
2
2
2 sin α M sin
1
2
sin
2
2
.
(5.65)
In some cases, measuring errors of time intervals τ 1 and τ 2 are equal, i.e., σ τ 1 =
σ τ 2 = σ τ , then:
σ r =
cσ τ
2 sin α M sin
1
2
sin
2
2
sin
2
1
2
+ sin
2
2
2
.
(5.66)
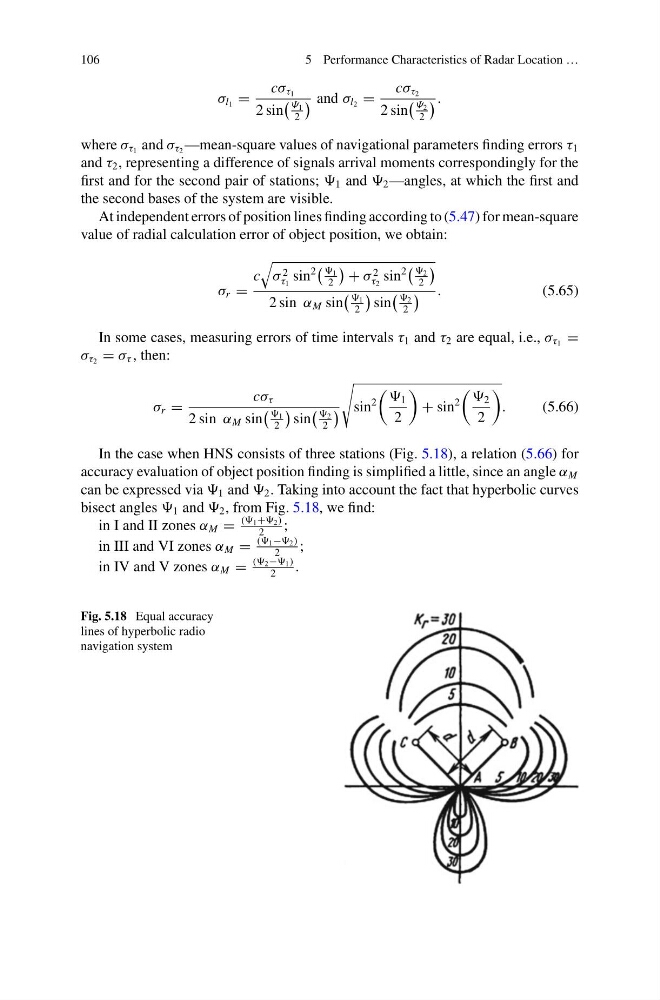
In the case when HNS consists of three stations (Fig. 5.18), a relation (5.66) for
accuracy evaluation of object position finding is simplified a little, since an angle α M
can be expressed via 1 and 2 . Taking into account the fact that hyperbolic curves
bisect angles 1 and 2 , from Fig. 5.18, we find:
in I and II zones α M =
(1+2)
2
;
in III and VI zones α M =
(1−2)
2
;
in IV and V zones α M =
(2−1)
2
.
Fig. 5.18 Equal accuracy
lines of hyperbolic radio
navigation system