

98
5 Performance Characteristics of Radar Location …
In practice, there is one case of interest, when accuracy of position lines finding
AB and CD is similar (which is encountered, particularly, at changes of single-type
equipment) and changes of navigational parameters are independent. In this case (at
α M ≤
π
2
), an ellipse of errors semi-axis sizes is equal:
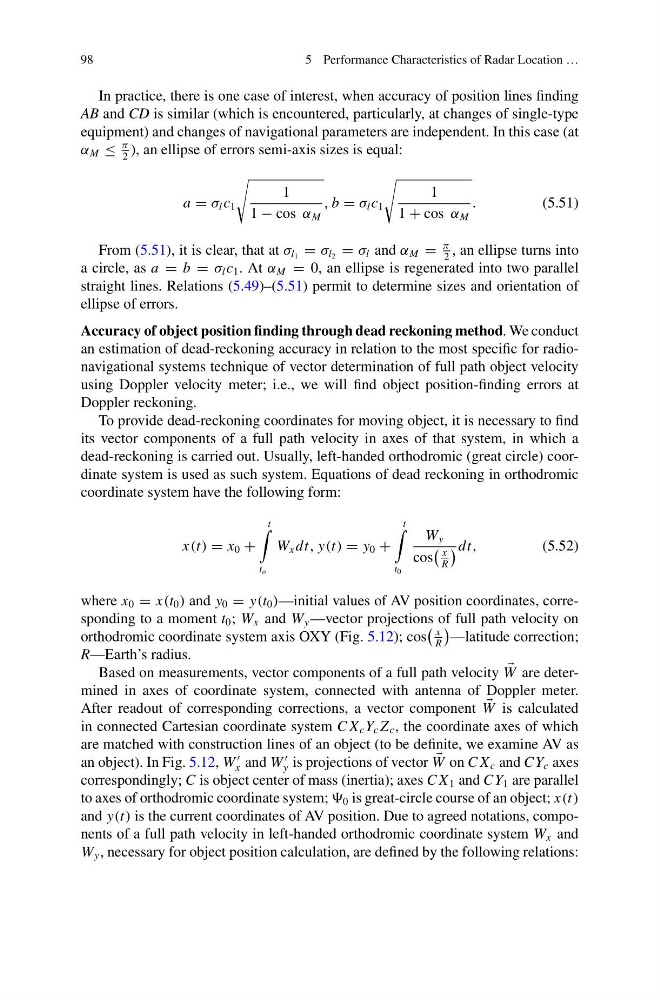
a = σ l c 1
1
1 − cos α M
, b = σ l c 1
1
1 + cos α M
.
(5.51)
From (5.51), it is clear, that at σ l 1 = σ l 2 = σ l and α M =
π
2
, an ellipse turns into
a circle, as a = b = σ l c 1 . At α M = 0, an ellipse is regenerated into two parallel
straight lines. Relations (5.49)–(5.51) permit to determine sizes and orientation of
ellipse of errors.
Accuracy of object position finding through dead reckoning method. We conduct
an estimation of dead-reckoning accuracy in relation to the most specific for radionavigational systems technique of vector determination of full path object velocity
using Doppler velocity meter; i.e., we will find object position-finding errors at
Doppler reckoning.
To provide dead-reckoning coordinates for moving object, it is necessary to find
its vector components of a full path velocity in axes of that system, in which a
dead-reckoning is carried out. Usually, left-handed orthodromic (great circle) coordinate system is used as such system. Equations of dead reckoning in orthodromic
coordinate system have the following form:
x(t) = x 0 +
t
t o
W x dt, y(t) = y 0 +
t
t 0
W y
cos
x
R
dt,
(5.52)
where x 0 = x(t 0 ) and y 0 = y(t 0 )—initial values of AV position coordinates, corresponding to a moment t 0 ; W x and W y —vector projections of full path velocity on
orthodromic coordinate system axis OXY (Fig. 5.12); cos
x
R
—latitude correction;
R—Earth’s radius.
Based on measurements, vector components of a full path velocity
W are determined in axes of coordinate system, connected with antenna of Doppler meter.
After readout of corresponding corrections, a vector component
W is calculated
in connected Cartesian coordinate system C X c Y c Z c , the coordinate axes of which
are matched with construction lines of an object (to be definite, we examine AV as
an object). In Fig. 5.12, W
x and W
y is projections of vector
W on C X c and CY c axes
correspondingly; C is object center of mass (inertia); axes C X 1 and CY 1 are parallel
to axes of orthodromic coordinate system; 0 is great-circle course of an object; x(t)
and y(t) is the current coordinates of AV position. Due to agreed notations, components of a full path velocity in left-handed orthodromic coordinate system W x and
W y , necessary for object position calculation, are defined by the following relations: