

94
5 Performance Characteristics of Radar Location …
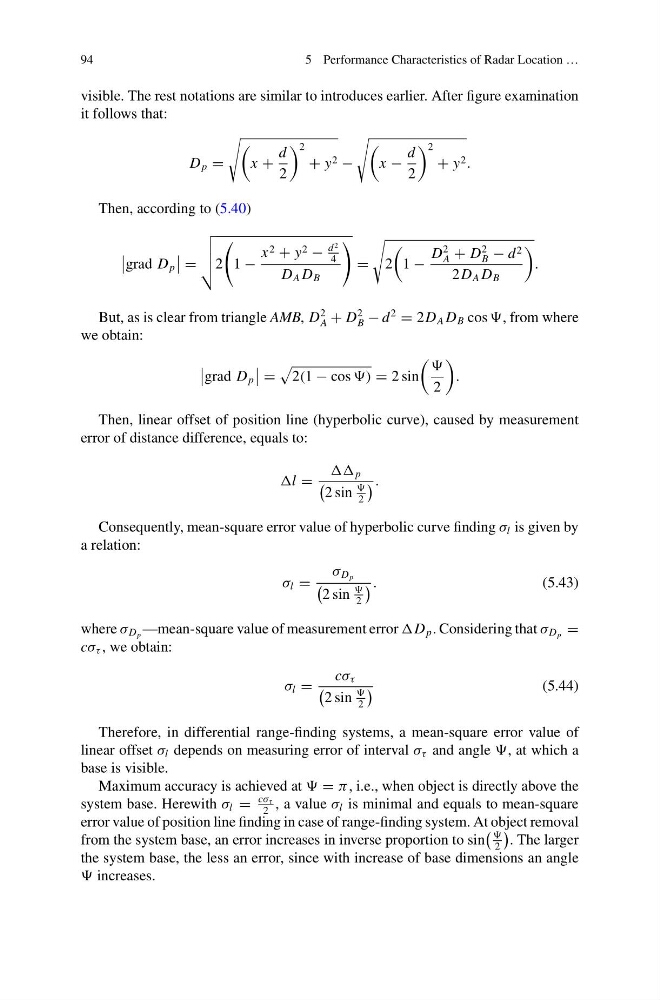
visible. The rest notations are similar to introduces earlier. After figure examination
it follows that:
D p =
x +
d
2
2
+ y 2 −
x −
d
2
2
+ y 2 .
Then, according to (5.40)
grad D p
=
2
1 −
x 2 + y 2 −
d 2
4
D A D B
=
2
1 −
D
2
A + D
2
B − d 2
2D A D B
.
But, as is clear from triangle AMB, D
2
A + D
2
B − d
2
= 2D A D B cos , from where
we obtain:
grad D p
=
2(1 − cos ) = 2 sin
2
.
Then, linear offset of position line (hyperbolic curve), caused by measurement
error of distance difference, equals to:
l =
p
2 sin
2
.
Consequently, mean-square error value of hyperbolic curve finding σ l is given by
a relation:
σ l =
σ D p
2 sin
2
.
(5.43)
where σ D p —mean-square value of measurement error D p . Considering that σ D p =
cσ τ , we obtain:
σ l =
cσ τ
2 sin
2
(5.44)
Therefore, in differential range-finding systems, a mean-square error value of
linear offset σ l depends on measuring error of interval σ τ and angle , at which a
base is visible.
Maximum accuracy is achieved at = π , i.e., when object is directly above the
system base. Herewith σ l =
cσ τ
2
, a value σ l is minimal and equals to mean-square
error value of position line finding in case of range-finding system. At object removal
from the system base, an error increases in inverse proportion to sin
2
. The larger
the system base, the less an error, since with increase of base dimensions an angle
increases.