

318
6 Visco-Plasticity
6.2.2 Specific Perzyna Model: Algorithmic Update
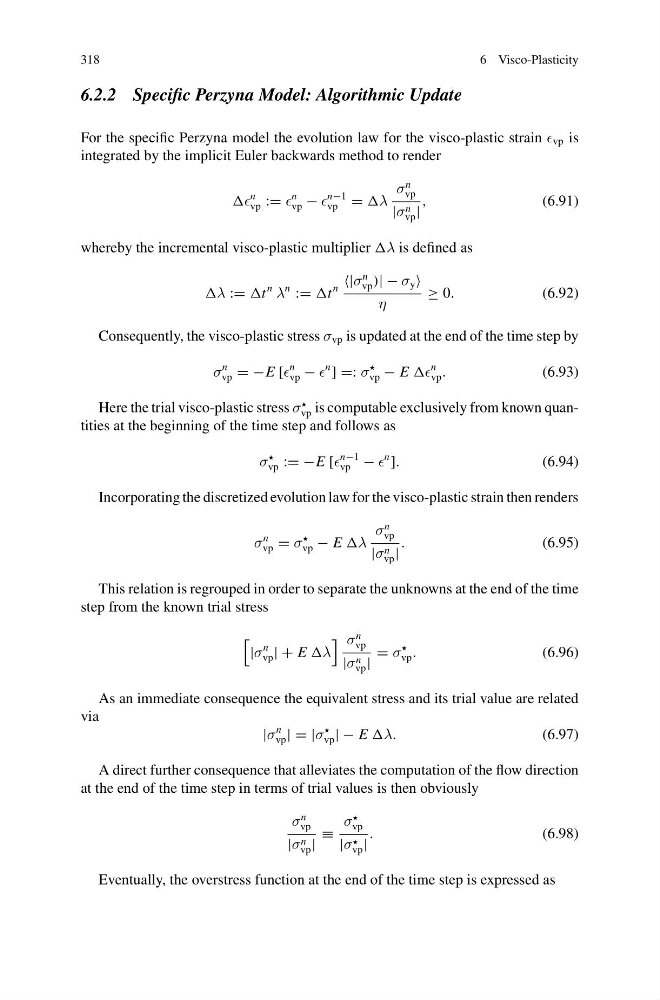
For the specific Perzyna model the evolution law for the visco-plastic strain vp is
integrated by the implicit Euler backwards method to render
n
vp :=
n
vp −
n−1
vp = λ
σ
n
vp
|σ n
vp |
,
(6.91)
whereby the incremental visco-plastic multiplier λ is defined as
λ := t
n
λ
n
:= t
n
|σ
n
vp )| − σ y
η
≥ 0.
(6.92)
Consequently, the visco-plastic stress σ vp is updated at the end of the time step by
σ
n
vp = −E [
n
vp −
n
] =: σ
vp − E
n
vp .
(6.93)
Here the trial visco-plastic stress σ
vp is computable exclusively from known quantities at the beginning of the time step and follows as
σ
vp := −E [
n−1
vp −
n
].
(6.94)
Incorporating the discretized evolution law for the visco-plastic strain then renders
σ
n
vp = σ
vp − E λ
σ
n
vp
|σ n
vp |
.
(6.95)
This relation is regrouped in order to separate the unknowns at the end of the time
step from the known trial stress
|σ
n
vp | + E λ
σ
n
vp
|σ n
vp |
= σ
vp .
(6.96)
As an immediate consequence the equivalent stress and its trial value are related
via
|σ
n
vp | = |σ
vp | − E λ.
(6.97)
A direct further consequence that alleviates the computation of the flow direction
at the end of the time step in terms of trial values is then obviously
σ
n
vp
|σ n
vp |
≡
σ
vp
|σ
vp |
.
(6.98)
Eventually, the overstress function at the end of the time step is expressed as