

4.5 Generalized-Maxwell Model
179
Incorporating the discretized evolution law for the viscous strain then renders
σ
n
v = E m
e − E m
t
n
η m
σ
n
v .
(4.229)
The above relation is regrouped in order to separate the unknowns at the end of
the time step from the known trial strain
τ m + t
n
η m
σ
n
v =
e .
(4.230)
Here the definition for the relaxation time τ m := η m /E m has been incorporated.
Thus the total and the viscous stress and the increment of the viscous strain read at
the end of the time step
σ
n
= σ
n
v + E ∞
n with σ
n
v =
η m
τ m + t n
e and
n
v =
t
n
τ m + t n
e . (4.231)
The sensitivity of σ
n with respect to
n is denoted the algorithmic tangent E a (thus
dσ = E a d) and is straightforwardly computed as
∂ σ
n
=
η m
τ m + t n + E ∞ .
(4.232)
Note that, consequently, the algorithmic tangent degenerates to E a → E ∞ + E m
for t
n
→ 0, i.e. for very fast processes (as compared to the relaxation time) the
response is (stiff) elastic. Likewise, for a rigid (elastic) spring with E m → ∞ and thus
for a vanishing relaxation time τ m → 0 the algorithmic tangent degenerates to the
case of the Kelvin model. Finally, for vanishing viscosity η m → 0 or for t
n
→ ∞,
i.e. for very slow processes (as compared to the relaxation time) the algorithmic
tangent degenerates to E a → E ∞ , i.e. the response is (soft) elastic.
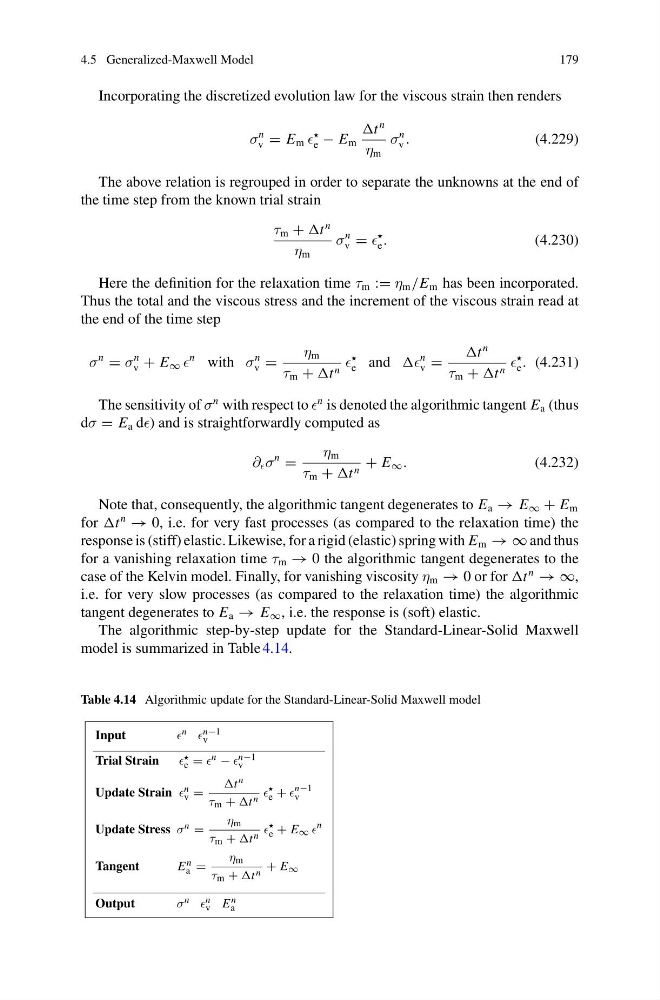
The algorithmic step-by-step update for the Standard-Linear-Solid Maxwell
model is summarized in Table 4.14.
Table 4.14 Algorithmic update for the Standard-Linear-Solid Maxwell model
Input
n n−1
v
Trial Strain
e = n − n−1
v
Update Strain n
v =
t n
τ m + t n
e +
n−1
v
Update Stress σ n =
η m
τ m + t n
e + E ∞
n
Tangent
E n
a =
η m
τ m + t n + E ∞
Output
σ n n
v E n
a