

4.2 Kelvin Model
107
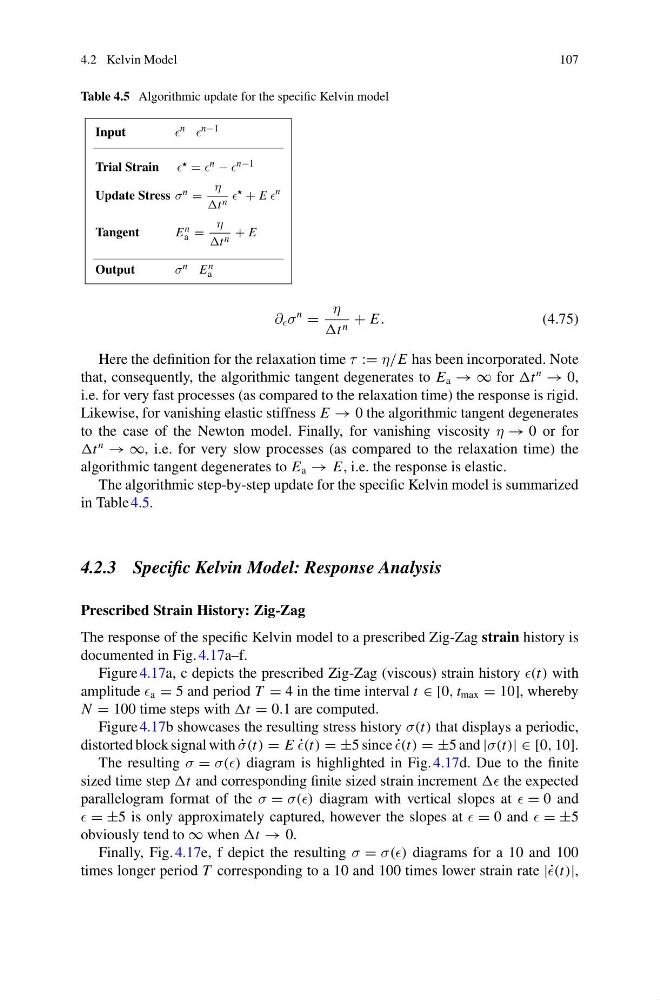
Table 4.5 Algorithmic update for the specific Kelvin model
Input
n n−1
Trial Strain = n − n−1
Update Stress σ n =
η
t n
+ E
n
Tangent
E n
a =
η
t n + E
Output
σ n E n
a
∂ σ
n
=
η
t n + E.
(4.75)
Here the definition for the relaxation time τ := η/E has been incorporated. Note
that, consequently, the algorithmic tangent degenerates to E a → ∞ for t
n
→ 0,
i.e. for very fast processes (as compared to the relaxation time) the response is rigid.
Likewise, for vanishing elastic stiffness E → 0 the algorithmic tangent degenerates
to the case of the Newton model. Finally, for vanishing viscosity η → 0 or for
t
n
→ ∞, i.e. for very slow processes (as compared to the relaxation time) the
algorithmic tangent degenerates to E a → E, i.e. the response is elastic.
The algorithmic step-by-step update for the specific Kelvin model is summarized
in Table 4.5.
4.2.3 Specific Kelvin Model: Response Analysis
Prescribed Strain History: Zig-Zag
The response of the specific Kelvin model to a prescribed Zig-Zag strain history is
documented in Fig. 4.17a–f.
Figure 4.17a, c depicts the prescribed Zig-Zag (viscous) strain history (t) with
amplitude a = 5 and period T = 4 in the time interval t ∈ [0, t max = 10], whereby
N = 100 time steps with t = 0.1 are computed.
Figure 4.17b showcases the resulting stress history σ(t) that displays a periodic,
distorted block signal with ˙
σ(t) = E ˙
(t) = ±5 since ˙
(t) = ±5 and |σ(t)| ∈ [0, 10].
The resulting σ = σ() diagram is highlighted in Fig. 4.17d. Due to the finite
sized time step t and corresponding finite sized strain increment the expected
parallelogram format of the σ = σ() diagram with vertical slopes at = 0 and
= ±5 is only approximately captured, however the slopes at = 0 and = ±5
obviously tend to ∞ when t → 0.
Finally, Fig. 4.17e, f depict the resulting σ = σ() diagrams for a 10 and 100
times longer period T corresponding to a 10 and 100 times lower strain rate |˙ (t)|,