

100
4 Visco-Elasticity
0
1
2
3
t
E(t)/η = δ(t) + H(t)/τ
∞
(t) 0 = H(t)
0
1
2
3
0
1
2
3
0
1
2
3
t
C(t)/C = H(t) [1 − e
−t/τ ]
τ
σ(t)/σ0 = H(t)
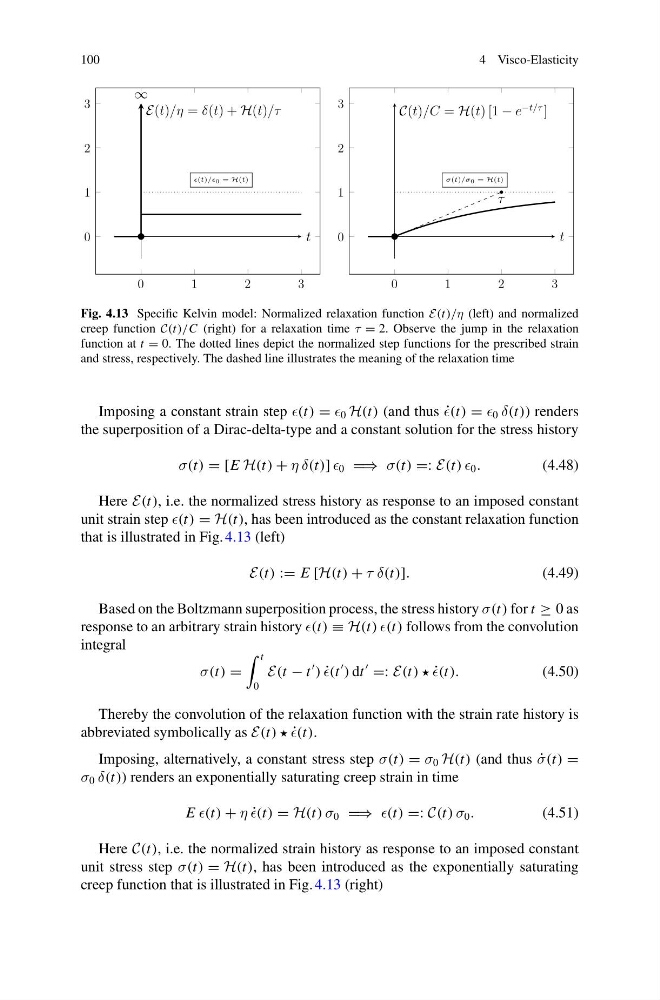
Fig. 4.13 Specific Kelvin model: Normalized relaxation function E(t)/η (left) and normalized
creep function C(t)/C (right) for a relaxation time τ = 2. Observe the jump in the relaxation
function at t = 0. The dotted lines depict the normalized step functions for the prescribed strain
and stress, respectively. The dashed line illustrates the meaning of the relaxation time
Imposing a constant strain step = 0 H(t) (and thus ˙
= 0 δ(t)) renders
the superposition of a Dirac-delta-type and a constant solution for the stress history
σ(t) = [E H(t) + η δ(t)] 0 =⇒ σ(t) =: E(t) 0 .
(4.48)
Here E(t), i.e. the normalized stress history as response to an imposed constant
unit strain step = H(t), has been introduced as the constant relaxation function
that is illustrated in Fig. 4.13 (left)
E(t) := E [H(t) + τ δ(t)].
(4.49)
Based on the Boltzmann superposition process, the stress history σ(t) for t ≥ 0 as
response to an arbitrary strain history ≡ H(t) follows from the convolution
integral
σ(t) =
t
0
E(t − t
) ˙
) dt
=: E(t) ) ˙
(4.50)
Thereby the convolution of the relaxation function with the strain rate history is
abbreviated symbolically as E(t) ) ˙
Imposing, alternatively, a constant stress step σ(t) = σ 0 H(t) (and thus ˙
σ(t) =
σ 0 δ(t)) renders an exponentially saturating creep strain in time
E + η ˙
= H(t) σ 0 =⇒ =: C(t) σ 0 .
(4.51)
Here C(t), i.e. the normalized strain history as response to an imposed constant
unit stress step σ(t) = H(t), has been introduced as the exponentially saturating
creep function that is illustrated in Fig. 4.13 (right)